RROrg/rr compiles a Redpill Recovery bootloader for x86 NAS hardware
Redpill Recovery (arpl-i18n)
At a glance
- What is it?
- RROrg/rr is a Shell project that builds a preinstallation and recovery environment so Synology DSM can run self-centralized on a local x86/x64 machine. It offers a Proxmox one-liner, a QEMU Compose file, a spreadsheet-driven model list, and gettext translations, with no rollback path, no in-tree GPU driver, and no commercial use.
- Who is it for?
- rr fits one specific job: people with x86/x64 hardware who want a Synology DSM preinstallation and recovery environment and can accept that the network fetch, the spreadsheet-driven model list, and the absence of a documented undo are all part of the deal. Anyone who needs rollback, an in-tree GPU driver, other CPU architectures, or commercial licensing has to look elsewhere or put the risk in writing first.
- Can I use it commercially?
- Yes, with conditions. GPL-3.0 is a copyleft licence: if you distribute software that includes it, you must release that software's source code under the same licence. Running it internally without distributing it does not trigger that obligation.
- Is it still maintained?
- Yes. The repository last received commits 58 days ago.
- What is it written in?
- Mainly Shell, according to GitHub's language statistics.
Answers come from the project's GitHub data, last synced on November 15, 2026, and from our analysis. They are not legal advice.
Star history
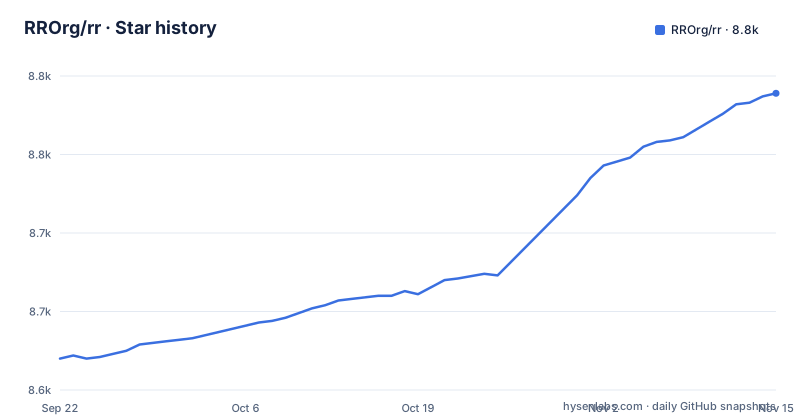
- RROrg/rr8,789 ★ · +169
| Repository | 2026-09-22 | 2026-11-15 |
|---|---|---|
| RROrg/rr | 8.6k | 8.8k |
169 Stars in the last 54 days, measured from the daily GitHub snapshot. Compare with other projects
Editorial analysis
The compile step needs the network, so offline means someone else built the image
Every build of rr reaches the network before it produces anything, because the compile step queries model and version information and then downloads the corresponding ROM. Offline does not degrade the build, it stops it, so a machine without connectivity produces no bootloader at all. The project's answer is RR-CUSTOM at https://rrorg.github.io/rr/, through which you build a pre-compiled bootloader for exactly that case. The two workflows carry very different risk, and the README's own disclaimer states that a user-specific custom modification of the tested and prebuilt bootloader images could cause irreversible data destruction.
The tree is small and mostly shell. The top level holds .editorconfig, .gitattributes, .github/, .gitignore, LICENSE, README.md, TODO, VERSION, docs/, files/, guide.md, scripts/, update-check.sh, and update-list.yml, so the shell payloads live under files/ and the entry points under scripts/, with VERSION carrying the version string. Releases follow a calendar scheme: 26.9.0 shipped on 2026-09-04, 26.8.2 on 2026-08-30, and 26.8.1 on 2026-08-13, and the last commit to main landed on 2026-09-18. Three tagged builds in four weeks on a date-numbered version is a moving target for anyone who pins by number and assumes the tag is stable.
The Proxmox path pipes a remote script into bash and then guesses your disk bus
Proxmox VE users get one command that fetches a script and hands it to bash, with arguments after the delimiter:
curl -fsSL https://github.com/RROrg/rr/raw/refs/heads/main/scripts/pve.sh | bash -s -- --bltype usb

# Optional Parameters:
--onboot <0|1>           Enable VM on boot, default 1 (enable)
--efi <0|1>              Enable UEFI boot, default 1 (enable)
--bltype <sata|usb|nvme> Bootloader disk type, default sata
--storage <name>         Storage name for images, as local-lvm, default auto get
--v9ppath <path>         Set to /path/to/9p to mount virtio 9p share
--vfsdirid <dirid>       Set to <dirid> to mount virtio fs share
--tag <tag>              Image tag, download latest re
Four flags carry defaults, and three of them decide where the machine ends up looking for a bootloader. The default --bltype is sata, so you pass --bltype nvme or --bltype usb yourself if you want a different bootloader disk type. --onboot and --efi both default to 1, so the VM is enabled on boot and uses UEFI unless you pass --onboot 0 or --efi 0. --tag is the flag that decides which image you actually receive: leave it alone and you take whatever is newest at the moment the script runs, so two people issuing the same command hours apart can land on different versions.
Model support lives in four spreadsheets you have to download and open by hand
The README publishes rr's model, PAT, addon and module lists as four spreadsheets under docs/: models, pats, addons, and modules. To find out whether your board has a PAT identifier, you download models.xlsx, open it in a spreadsheet program, and read it yourself. Git history is no friendlier here: an .xlsx file is a zip archive, so a change to the supported model list produces a binary diff that reviewers cannot read. The README also links a driver lookup page at https://rrorg.github.io/rr/modules.html.
The Compose path pins qemu to latest and leaves the image file to the reader
The container path assumes you already have the artifact, and the listing says so in its own comments: download the rr.img file from the latest release and replace the placeholder with the actual path to your file. Nothing in the file fetches it for you.
# 请从最新版本中下载 rr.img 文件。
# 并将 <path_to_rr.img> 替换为你的 rr.img 文件的实际路径.
# Please download the rr.img file from the latest release.
# And replace <path_to_rr.img> with the actual path to your rr.img file.

version: "3.9"
services:
  rr:
    image: qemux/qemu:latest
    container_name: rr
    environment:
      BOOT: ""
      RAM_SIZE: "4G"  # >= 4G recommended for DSM
      CPU_CORES: "2"
      DISK_FMT: "qcow2"
      DISK_TYPE: "sata"
      DISK_SIZE: "32G"  # data disk size
      ARGUMENTS: "-device nec-usb-xhci,id=usb0,multifunction=on -drive file=/rr.img,
Two details there will cost you time. The image is qemux/qemu:latest, so pulling the same Compose file again can change the QEMU build underneath a virtual machine you already created, and there is no digest or version tag holding it still. And the ARGUMENTS value stops mid-drive specification, at a comma after the file path, with no closing quote, so the listing as printed is not valid YAML and the remaining QEMU flags have to come from somewhere other than it. RAM_SIZE carries the note that 4G is recommended for DSM, which makes the floor explicit: a smaller VM is not a cheaper option, it is a smaller one that DSM was not sized for.
The disclaimer puts irreversible data loss on the person holding the disk
The opening section of the README is a liability notice and it is unusually direct. The Chinese line says hard drives have a price while data does not, and that any change to the bootloader carries risk. The English version spells out the consequence: a user-specific custom modification of the tested and prebuilt bootloader images could cause irreversible data destruction on the local machine, and RROrg accepts no responsibility for damage or loss of any kind. The project is also released for educational and learning purposes only, with commercial application strictly prohibited.
What that wording means for a reader is concrete. There is no support commitment behind it, so a failed flash is a private problem with your own disks rather than an incident anyone answers for. A NAS is usually the machine holding a household's or a small office's data, and irreversible destruction of it is the failure mode being described. The commercial prohibition adds a second limit: a company that wants to standardise on rr for its own customers has no sanctioned path inside this project, and would have to settle licensing and support on its own before going anywhere near a production deployment.
Language files are extracted from shell strings and the update step is cut off
Localisation runs through gettext pointed at the shell sources, so the translatable strings are whatever rr's scripts pass through the TEXT keyword. The documented sequence is:
# If deletion nor addition proces of code hunk is not required, comply with the following process
sudo apt install gettext
git clone https://github.com/rrorg/rr.git
cd files/initrd/opt/rr
xgettext -L Shell --keyword=TEXT *.sh -o lang/rr.pot
sed -i 's/charset=CHARSET/charset=UTF-8/' lang/rr.pot
# If you have to replace certain language string of the project, please suggest and modify translation changes within each correlated PO file
mkdir -p lang/zh_CN/LC_MESSAGES
msginit -i lang/rr.pot -l zh_CN.UTF-8 -o lang/zh_CN/LC_MESSAGES/rr.po
# Update translation files
for
That sequence stops at the word for, right after the comment about updating translation files, so the loop that would compile the catalogs is cut off in the guide. A translator can regenerate the POT and create a new PO file from the steps shown, but the compile-and-install half of the cycle is not written down, and the last mile of getting a translation into a built image has to be worked out from the tree itself. The maintenance list shows who owns each locale, and it also shows that en_US, zh_CN, and zh_HK sit with the same rrorg account while de_DE, ja_JP, ko_KR, ru_RU, tr_TR, vi_VN, and zh_TW have named outside maintainers.
The gaps rr leaves open: rollback, GPU drivers, other architectures, memory
Four things a reader will look for are not in this project. First, rollback: the README does not document a way to undo a bootloader flash. Second, a GPU driver. Every graphics entry is an outside link, with vGPU pointing at syno_nvidia_gpu_driver and a separate blog, and iGPU pointing at Jim's Blog and intel-gpu-i915-backports. The iGPU module the README credits, intel-gpu-i915-backports, lives in an outside repository (MoetaYuko), so graphics support depends on projects outside rr. Third, other CPU architectures: the project describes itself as running Synology DSM on any local machine with any x86/x64 CPU architecture, which places everything else outside its scope. Fourth, headroom, since 4G is marked as recommended for DSM.
Editorial conclusion
rr fits one specific job: people with x86/x64 hardware who want a Synology DSM preinstallation and recovery environment and can accept that the network fetch, the spreadsheet-driven model list, and the absence of a documented undo are all part of the deal. Anyone who needs rollback, an in-tree GPU driver, other CPU architectures, or commercial licensing has to look elsewhere or put the risk in writing first. Before touching real disks, check that your model identifier appears in the models sheet and decide which image tag you are pinning.
Frequently asked questions
What does RROrg/rr actually produce?
It compiles a prebuilt bootloader and a preinstallation and recovery environment so Synology DSM can be self-centralized on a local x86/x64 machine instead of on Synology hardware. The compile stage needs the model and version information and the corresponding ROM, all fetched from the network.
Can I install RROrg/rr on Proxmox without compiling anything?
Yes, through the one-click script, which fetches pve.sh and passes it to bash. Its flags cover VM on boot, UEFI, bootloader disk type, storage name, 9p and virtiofs shares, and the image tag. On boot and UEFI default to enabled, and the bootloader disk type defaults to sata.
What does RROrg/rr not do for me?
It does not document a rollback path for a failed flash, it ships no GPU driver of its own since every graphics entry points at an outside project, and it targets x86/x64 machines only. Its Docker Compose example also marks 4G of memory as recommended for DSM.
How do I get a bootloader image without internet access?
Not with the local compile step. The README tells users who cannot connect to the Internet to build a pre-compiled bootloader through RR-CUSTOM at https://rrorg.github.io/rr/, because compiling requires the network to obtain model and version information and download the matching ROM.
How is a new language translation contributed to RROrg/rr?
Install gettext, clone the repository, run xgettext over the shell sources with the TEXT keyword to produce lang/rr.pot, fix the charset entry, then create a PO file per language with msginit. German, Japanese, Korean, Russian, Turkish, Vietnamese, and Traditional Chinese (zh_TW) have named community maintainers.
Official sources
Add this badge to your README
If you maintain this project, the badge below links readers to this analysis and shows its maintenance status from the daily GitHub snapshot. Paste the markdown into your README; add ?metric=license or ?metric=stars to the image URL for a different field.
[](https://hysenlabs.com/projects/rrorg-rr)Star history chart for your README
[](https://hysenlabs.com/projects/rrorg-rr)Was this useful?