The algorithm shipped as a commit, ROS2 lives on a branch
SCAN-Planner: Spatial Collision-Aware Local planning for Route-Guided Long-Range Quadruped Navigation
At a glance
- What is it?
- SCAN-Planner is a spatial collision-aware local planner for quadruped navigation, built on EGO-Planner with a simulator assembled from three other projects. Its install path is ROS Noetic and catkin_make, its three navigation modes point at three different tools, and the ROS2 interface lives on a branch the quick start never mentions.
- Who is it for?
- Use it if you already work in ROS Noetic and want EGO-Planner's local planning with multi-floor support. Two things to check before you start: the borrowed stack is not documented, since the simulator is adapted from MARSIM with map generation and trotting motion from two other projects and nothing says how that code arrives, and the ROS2 interface is on a branch rather than the default one, so the install steps you have will not cover it.
- Can I use it commercially?
- Yes. Apache-2.0 is a permissive licence: you can use, modify and sell software built on it, as long as you keep its copyright and licence notices.
- Is it still maintained?
- Yes. The repository last received commits 109 days ago.
- What is it written in?
- Mainly C++, according to GitHub's language statistics.
Answers come from the project's GitHub data, last synced on November 15, 2026, and from our analysis. They are not legal advice.
Star history
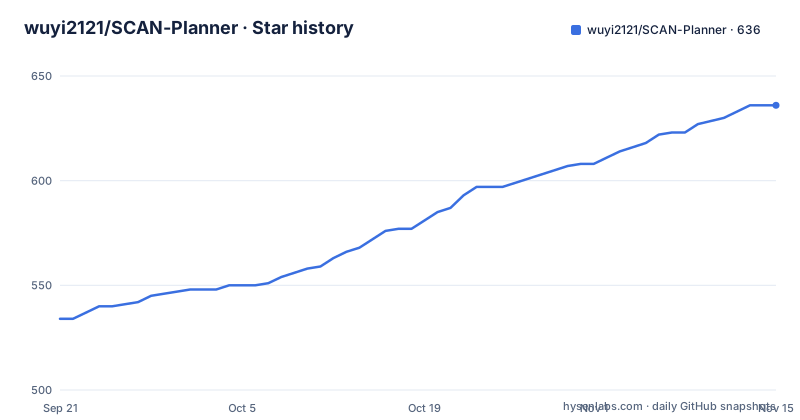
- wuyi2121/SCAN-Planner636 ★ · +102
| Repository | 2026-09-21 | 2026-11-15 |
|---|---|---|
| wuyi2121/SCAN-Planner | 534 | 636 |
102 Stars in the last 55 days, measured from the daily GitHub snapshot. Compare with other projects
Editorial analysis
The algorithm shipped as a commit, not a release
The news block has three dated entries. On Jul 9, 2026 the main algorithm of SCAN-Planner was released. On Jul 13 a community contributor added ROS2 support. On Jul 29 CAD files for the sensor layout became available. The repository itself was last pushed on 2026-07-29, the same day as the hardware note.
There are no GitHub releases and no tags to match those words against. So the word release in the Jul 9 entry means a commit on the default branch, and the version you get is whatever the tip of main holds. For a robotics codebase that is a real constraint: there is no known-good commit to pin, and the branches diverge, because the ROS2 interface went to ros2-community rather than to main.
The citation is the only stable identifier, an arXiv preprint numbered 2606.19555, listed under a BibTeX entry typed as an article with the preprint as its journal.
The install path is Noetic, the ROS2 path is elsewhere
The installation section is dated and narrow: tested on Ubuntu 20.04 with ROS Noetic, with Armadillo installed because the simulator requires it, then a clone and a catkin build.
sudo apt-get install libarmadillo-devgit clone https://github.com/wuyi2121/SCAN-Planner.git
cd SCAN-Planner
catkin_makeNo other platform is named, and the quick start is built around the catkin workspace layout, with two terminals sourcing `devel/setup.bash` and launching `scan_planner rviz.launch` and `scan_planner run.launch`.
That is all ROS 1. The ROS2 interface, contributed in July 2026, sits on the ros2-community branch, and this repository contains no ROS2 install instructions, no workspace build for it, and no statement about which of the launch options below apply there. Anyone arriving from the ROS2 side has to work that out from the branch itself.
Three navigation modes behind one integer
One launch option, `navi_mode`, selects between three interfaces that do not share a toolchain. Mode 1 is interactive 2D Nav Goal, driven from RViz. Mode 2 is keypoint-based multi-floor navigation, documented in `tools/README.md`. Mode 3 is reference-path tracking with local obstacle avoidance, and its documentation is not in this repository at all, it points at TravExplorer.
So a single integer decides whether you are clicking a goal in a simulator, authoring keypoints, or handing a reference path to another project entirely.
The note attached to that option is the practical warning: if the robot cannot climb stairs, increase the z height of the body, the keypoints, or the initial path. There is no stair-climbing capability listed anywhere, so a multi-floor route is a geometry problem you solve by editing heights rather than a feature you switch on.
is_real_world switches which topic names exist
The other two documented options are small and load-bearing. `is_real_world` is set to true when running against real robot topics, `body_pose_topic` and `sensor_pose_topic`, and false when testing with the simulator. One flag, two different sets of subscriptions, and a wrong value gives you a planner waiting on topics nobody publishes.
`sensor_type` picks the input hardware: `lidar` for point-cloud sensors, with the MID360 named as an example, and `depth` for depth cameras, with the RealSense D435 named. That is the whole compatibility statement, two sensor families and two example devices.
Everything else lives in `advanced_param.xml`, and the README says plainly that the defaults are tuned for the Unitree Go2 and should be adjusted for a different platform. Nothing in the visible text says which defaults are Go2-specific or what a wrong value does.
The simulator is three borrowed projects
The acknowledgements are the best description of the codebase available, because they name what was built on. The framework builds on EGO-Planner for local planning. The map representation is inspired by ROG-Map. The localization module is based on Elevator-LIO, itself a multi-floor extension of FAST-LIO2. High-level cross-floor exploration is handled by TravExplorer, which is the same author's other project.
The simulator is adapted from MARSIM, with map generation from Mockamap and trotting motion from Leg-KILO. That is a five-project dependency surface for one component, and the install instructions cover one of them, Armadillo as a library, without saying where MARSIM, Mockamap or Leg-KILO come from. The top-level listing is six entries, with src/ and tools/ doing all the work, so any of them must live inside src/, and no submodule or fetch step appears in the visible documentation.
Reproducing the results means reconstructing that tree first.
The GPU sensing path costs four development packages
Local sensing has two implementations, a CPU node called `pcl_render_node` and a GPU node called `opengl_render_node`. The CPU version is built by default, with compatibility given as the reason. Turning on the GPU build takes two steps: install the OpenGL development packages, then compile with the flag.
sudo apt-get install libglew-dev libglfw3-dev libgl1-mesa-dev libglu1-mesa-devcatkin_make -DUSE_GPU=ONA separate `use_gpu` option in `simulator.xml` then decides which sensing node launches. That gives two switches for one capability, a compile-time flag and a runtime choice, and nothing in the visible text explains what happens when the runtime choice disagrees with what was compiled. On a headless machine, which is the normal case for running the planner without RViz, the OpenGL packages are a dependency you will install whether or not you enable the GPU path.
The CAD files are in another account and a proprietary format
The hardware section offers CAD for the sensor layout in two formats, .SLDPRT and .STL, with the note that they open in Solidworks. The files are not in this repository. They live in a separate layout repository belonging to a co-author, linked from the Jul 29 news entry.
The stated reason is reproducibility, and the gesture is right, but the practical shape is a sensor mount that only one family of tools can edit natively, kept outside the repository whose licence you just accepted. The STL half is portable; the part file is not.
That leaves a small asymmetry worth noting against the rest of the project: the code is Apache-2.0 with a clear build path, while the physical part needed to reproduce the sensor arrangement lives elsewhere, in a format that ties you to one vendor's toolchain.
Editorial conclusion
Use it if you already work in ROS Noetic and want EGO-Planner's local planning with multi-floor support. Two things to check before you start: the borrowed stack is not documented, since the simulator is adapted from MARSIM with map generation and trotting motion from two other projects and nothing says how that code arrives, and the ROS2 interface is on a branch rather than the default one, so the install steps you have will not cover it.
Frequently asked questions
What is SCAN-Planner?
A spatial collision-aware local planner for quadruped navigation, described as a low-level planning foundation for upper-level tasks such as autonomous exploration and vision-language navigation. The paper is arXiv preprint 2606.19555.
How do I build SCAN-Planner?
On Ubuntu 20.04 with ROS Noetic, install libarmadillo-dev for the simulator, clone the repository, run catkin_make, then source devel/setup.bash before launching scan_planner rviz.launch and scan_planner run.launch in two terminals.
What do the navi_mode values do in SCAN-Planner?
Mode 1 is interactive 2D Nav Goal, mode 2 is keypoint-based multi-floor navigation documented in tools/README.md, and mode 3 is reference-path tracking with local obstacle avoidance, documented in the separate TravExplorer repository.
How do I enable the GPU sensing backend in SCAN-Planner?
Install libglew-dev, libglfw3-dev, libgl1-mesa-dev and libglu1-mesa-dev, then compile with catkin_make -DUSE_GPU=ON. The CPU node pcl_render_node is built by default, and the use_gpu option in simulator.xml selects which sensing node launches.
Does SCAN-Planner support ROS2?
A ROS2 interface was contributed by the community in July 2026 and lives on the ros2-community branch. The installation and quick start in the README cover the ROS Noetic path only.
Official sources
Add this badge to your README
If you maintain this project, the badge below links readers to this analysis and shows its maintenance status from the daily GitHub snapshot. Paste the markdown into your README; add ?metric=license or ?metric=stars to the image URL for a different field.
[](https://hysenlabs.com/projects/wuyi2121-scan-planner)Star history chart for your README
[](https://hysenlabs.com/projects/wuyi2121-scan-planner)Was this useful?