jetson-containers: A Modular Build System for AI Packages on NVIDIA Jetson
Machine Learning Containers for NVIDIA Jetson and JetPack-L4T
At a glance
- What is it?
- dusty-nv/jetson-containers is a container build system that assembles AI/ML packages for NVIDIA Jetson and JetPack-L4T from per-package directories. It is aimed at Jetson owners who need CUDA-enabled PyTorch, TensorFlow, vLLM or ROS without hand-writing Dockerfiles, and it has no versioned GitHub releases.
- Who is it for?
- Adopt jetson-containers if you own Jetson hardware, need CUDA-enabled ML or robotics packages, and are willing to build images on the device. Do not adopt it if you need prebuilt multi-architecture images from a registry or you are not on Jetson at all.
- Can I use it commercially?
- Check first. The repository uses a licence we do not classify automatically, so read its LICENSE file before any commercial use.
- Is it still maintained?
- Yes. The repository last received commits 13 days ago.
- What is it written in?
- Mainly Jupyter Notebook, according to GitHub's language statistics.
Answers come from the project's GitHub data, last synced on November 15, 2026, and from our analysis. They are not legal advice.
Star history
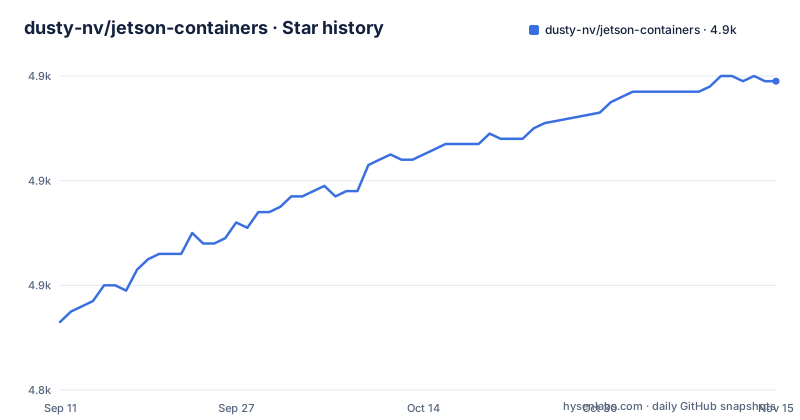
- dusty-nv/jetson-containers4,899 ★ · +46
| Repository | 2026-09-11 | 2026-11-15 |
|---|---|---|
| dusty-nv/jetson-containers | 4.9k | 4.9k |
46 Stars in the last 65 days, measured from the daily GitHub snapshot. Compare with other projects
Editorial analysis
What jetson-containers solves for Jetson owners
Installing PyTorch or TensorFlow on a Jetson is not the same problem as installing it on an x86 server. The wheels published on PyPI are built for x86 and desktop CUDA, so a Jetson user typically ends up compiling against the board's JetPack-L4T stack or hunting for a vendor wheel that matches the exact L4T version. The README frames jetson-containers as a "modular container build system" that provides current AI/ML packages for NVIDIA Jetson, with the package index hosted at pypi.jetson-ai-lab.io. The target user is someone with a Jetson board who wants a working CUDA build of a framework or inference server without maintaining that build themselves. The README's package table shows the intended breadth: machine learning frameworks, LLM serving stacks, vision-language and vision-transformer models, RAG components, L4T base images, CUDA bindings, and robotics packages such as ROS, LeRobot and OpenVLA. That range is the point. A single mechanism covers a Jetson Orin running vLLM and a Jetson running ROS 2 with a ZED camera.
The package directory is the unit of composition
The README's table links every entry to a directory under packages/, and the paths encode both category and name: packages/ml/pytorch, packages/llm/vllm, packages/vit/sam, packages/physicalAI/lerobot, packages/vectordb/faiss. That layout is the architecture. Each package directory carries its own build definition, and the system composes a container from the packages you name. The README describes the result as modular, and the directory tree supports that reading: packages are grouped by function (ml, llm, vlm, vit, rag, cuda, cv, hw, physicalAI) rather than by vendor. What can be confirmed is the naming convention: each package name in the table links to a directory path. The repository's primary language is listed as Jupyter Notebook, which is worth noting for anyone expecting a conventional Python build tool.
Getting a container running
The repository root holds build.sh, run.sh, install.sh and a jetson-containers script, and the README's table names the packages, each linked to its directory under packages/. Check the script's own help output for flags to select a base image, pin a version, or choose an output tag before assuming those options exist. The README also shows a status badge for pypi.jetson-ai-lab.io, which indicates that a package index is served for Jetson. That index is the source the build system pulls from when it installs AI/ML packages, and it is the reason the project can offer current package versions rather than only what ships inside the L4T base image. The repository has no published GitHub releases, so there is no versioned release artifact to download. The practical implication is that adoption means tracking the master branch and rebuilding when it changes. If you want a fixed reference point, record the commit hash you built from, because the repository itself is the version.
Where the build-on-device model breaks down
The most visible constraint is that this is a source build system. The README describes a modular container build system, and the build command runs a script in the repository. That means the heavy work happens wherever you run it. On a Jetson, compiling a large framework or an inference server can take a long time and can exhaust storage. If your deployment target is a fleet of Jetsons, building per device is a poor fit; you want a registry and a pull, not a compile. A second limitation is hardware scope. The project is explicitly for NVIDIA Jetson and JetPack-L4T. The package index at pypi.jetson-ai-lab.io is Jetson-oriented. A third issue is version alignment. Because packages are built against the board's L4T stack, a package that works on one JetPack release may not work on another. Treat the package table as a menu, not a guarantee that every entry builds on your board. Finally, the licence field on GitHub reports NOASSERTION, so the terms governing the repository and the images it produces are not stated in a standard identifier. Anyone planning to redistribute built images should read the repository's own licence file rather than relying on the GitHub label.
How it differs from NVIDIA's own L4T container images
The README itself lists L4T base images as packages: l4t-pytorch, l4t-tensorflow, l4t-ml, l4t-diffusion, l4t-text-generation under packages/ml/l4t. Those are the vendor-maintained containers that NVIDIA publishes for Jetson, and they are the obvious alternative. The difference in approach is composition. An L4T image is a fixed bundle assembled by the vendor: you take the combination it ships with. jetson-containers treats those same images as one category among many and builds a container from the packages you select, so you can pair, for example, a vision-transformer package with a specific inference runtime without waiting for a vendor bundle to include both. The trade is control against certainty. A vendor image is tested as a unit and pulled from a registry; a jetson-containers build is assembled on your machine from the current state of the repository and the package index. If your requirement is a known-good combination that someone else validated, the L4T images are the safer choice. If your requirement is a combination that does not exist as a bundle, jetson-containers is the mechanism that lets you express it.
Maintenance cost and what to verify before adopting
The repository has no published GitHub releases, so upgrades are not version-to-version events. They are pulls of the master branch followed by a rebuild. That shifts the maintenance burden onto the user in two ways: you must re-run the build to pick up changes, and you must notice when a package you depend on has moved or been renamed in the packages/ tree. The package index at pypi.jetson-ai-lab.io is a second moving part, since it supplies the AI/ML packages the build installs. The repository's last push date is recent, which suggests active development, but activity is not the same as stability for your specific combination. Before adopting, verify three things. First, read the licence file directly, because the GitHub metadata reports NOASSERTION and that tells you nothing about redistribution rights. Second, confirm that the package directory you need exists at the path shown in the README table and check its build definition for the L4T versions it targets. Third, decide whether you can build on the device or whether you need to build elsewhere and transfer the image, since build.sh is a script you run yourself. If you cannot answer all three, the L4T bundles are the lower-risk starting point.
Editorial conclusion
Adopt jetson-containers if you own Jetson hardware, need CUDA-enabled ML or robotics packages, and are willing to build images on the device. Do not adopt it if you need prebuilt multi-architecture images from a registry or you are not on Jetson at all. Before committing, verify the licence terms (GitHub reports NOASSERTION), confirm your L4T version is supported by the package you need, and check whether a prebuilt image exists for your target so you can skip a long local build.
Frequently asked questions
what is jetson containers
A modular container build system that provides AI and ML packages for NVIDIA Jetson and JetPack-L4T. It is organised as an index of package names, where each one links to its own directory under packages/, plus a compose stack that serves local PyPI and APT indexes for the CUDA variants with a fallback to the community registry.
how to install jetson containers
The repository has an install.sh script at the root next to run.sh, build.sh and launch_pypi.sh, a host toolchain listed in requirements.txt, and a local registry stack for the cu126, cu129 and cu130 variants that falls back to the Jetson community indexes.
how to use jetson containers
Start by picking a package from the index, which tells you the category directory that builds it, for example packages/ml/pytorch or packages/ml/l4t/l4t-pytorch. The compose stack named jetson-containers-local is described as compatible with the project and serves the wheels and debian packages a build pulls, one service per CUDA variant.
jetson containers vs docker
This project is a package build and delivery layer: one directory per AI and ML package under packages/, local PyPI and APT servers per CUDA variant with fallback URLs, and shell scripts named install.sh, run.sh and build.sh at the root.
Official sources
Add this badge to your README
If you maintain this project, the badge below links readers to this analysis and shows its maintenance status from the daily GitHub snapshot. Paste the markdown into your README; add ?metric=license or ?metric=stars to the image URL for a different field.
[](https://hysenlabs.com/projects/dusty-nv-jetson-containers)Star history chart for your README
[](https://hysenlabs.com/projects/dusty-nv-jetson-containers)Was this useful?