openbot: the disclaimer is step one of seven, and the language is Swift
OpenBot leverages smartphones as brains for low-cost robots. We have designed a small electric vehicle that costs about $50 and serves as a robot body. Our software stack for Android smartphones supports advanced robotics workloads such as person following and real-time autonomous navigation.
At a glance
- What is it?
- A project that uses a smartphone as a robot's brain, with a roughly fifty dollar electric vehicle as the body and separately flashed Arduino firmware underneath, described as an Android software stack supporting person following and real-time navigation. The seven starting points begin with a disclaimer that is translated into five languages, while the recorded primary language is Swift.
- Who is it for?
- OpenBot is worth reading if you have a phone and want to see what it can do as a robot's computer, because the split between an Arduino body and a phone brain is the whole idea and the project documents both halves. Four things to know before you build.
- Can I use it commercially?
- Yes. MIT is a permissive licence: you can use, modify and sell software built on it, as long as you keep its copyright and licence notices.
- Is it still maintained?
- Yes. The repository last received commits 2 days ago.
- What is it written in?
- Mainly Swift, according to GitHub's language statistics.
Answers come from the project's GitHub data, last synced on November 15, 2026, and from our analysis. They are not legal advice.
Star history
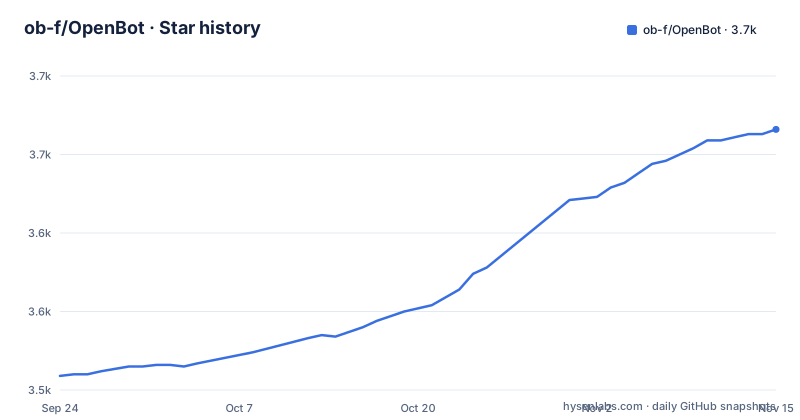
- ob-f/OpenBot3,666 ★ · +157
| Repository | 2026-09-24 | 2026-11-15 |
|---|---|---|
| ob-f/OpenBot | 3.5k | 3.7k |
157 Stars in the last 52 days, measured from the daily GitHub snapshot. Compare with other projects
Editorial analysis
The first instruction is to read a disclaimer
The getting-started section is a list of seven links, and the first one is not a build step.
It says to read the disclaimer. Only after that does it move on: build your own robot body, flash the Arduino firmware, install the Android apps, drive the robot through a controller, program it in a playground, and train your own driving policy.
So the ordering is deliberate. A project about putting a camera-equipped computer on a moving vehicle wants the reader to have read the terms before they solder anything, and it puts that first rather than in a footer.
What is striking is the translation coverage around it. The repository carries the disclaimer in five languages, the contributing guide in five, and the readme in five, each with a language suffix in the filename. The licence file is one file with no translations.
So the project has accepted the cost of keeping three documents synchronised across five languages, and has decided the disclaimer is worth that cost.
The robot is an Arduino and a phone, which is two processors
The design is stated in the first paragraph and it is worth unpacking.
OpenBot uses smartphones as the brains for low-cost robots. The project designed a small electric vehicle that costs about fifty dollars and serves as the robot body. The software stack described is for Android smartphones, and it is said to support workloads such as person following and real-time autonomous navigation.
The hardware therefore splits across two devices with a clear division of labour. The Arduino runs the firmware you flash onto the vehicle, and the smartphone runs the applications. There is a separate guide for each.
That has consequences that the readme does not spell out. Anything requiring deterministic timing belongs on the Arduino, and anything requiring a camera, a model or a screen belongs on the phone. Two processors also means two things to keep in sync and a wireless link between them, which is a failure mode a single-board design would not have.
The fifty dollar figure is for the body. It is not a claim about the total cost of the robot.
The recorded language is Swift and the described product is Android
There is a mismatch between what the repository statistics say and what the readme describes.
The recorded primary language is Swift. There is a directory for iOS at the top level. And the Android apps are step four of the seven getting-started steps.
So the project has an iOS client, and that client is large enough in the tree to be what the language statistics are measuring, while the documentation spends its words on the Android applications and on a vehicle build that needs a camera pointed forwards.
Neither side is documented in the readme. The iOS directory has no entry in the getting-started list, and no guide is linked for it, so a reader arriving from an iPhone has nothing to follow.
The practical reading is that Android is the supported path and iOS is present in the tree without a documented route. That is a reasonable state for a research project with limited maintainers, and it is still the first thing to confirm before planning around either platform.
Seven component guides, and three directories the list never mentions
The getting-started list doubles as the map of the repository, and it covers seven areas: the robot body, the firmware, the Android apps, the controller, the playground and the driving policy, with the disclaimer above them.
Six of those seven correspond to a directory in the tree, each with its own readme. That is a well-organised project: every component you have to assemble has instructions written for it rather than a single manual that mixes them.
Three top-level directories are not in the list. There is a directory for iOS, as mentioned. There is a Python directory, with no guide linked and no step describing what runs from it. And there is a documentation directory, which is where the seven guides' supporting reference belongs.
So seven of ten directories are documented in the list and three are not. For a project where the work is physical, that is a reasonable split, but it means the Python and iOS parts are things you will have to read rather than run.
The newest tag is about eighteen months older than the last push
The release history is three tags, and the spacing between them is uneven.
The newest is version 0.8.0 from March 2025. Before it, version 0.7.1 from May 2023, and version 0.7.0 three weeks earlier in the same month.
So there was a burst of work in May 2023, then roughly twenty-two months of nothing at the tag level, then a single release in March 2025.
The last push on the default branch is dated 2026-09-25, which puts the branch around eighteen months ahead of the newest tag. Whether that is steady maintenance or one long piece of work is not something the readme says, and there is no changelog in the tree to check.
There is no homepage release page either; the homepage field points at the project site rather than at a release feed. So the tag list in the readme is the only version history a reader gets.
Getting the source is offered three ways: a zip archive, a clone, or a fork followed by a clone, with forking recommended if you intend to contribute. The clone is a single line on the HTTPS transport:
git clone https://github.com/ob-f/OpenBot.gitFor anyone building from source, the practical consequence is to pick a tag deliberately rather than following the default branch, and to expect the component guides to be written for the tag rather than for the branch tip.
The citation is a 2021 conference paper with two authors
There is a citation section, and it asks you to cite a paper if you use the project.
The reference is given as a BibTeX entry with a language tag on the fence, an inproceedings key, a title, two authors, the proceedings of the International Conference on Robotics and Automation, and the year 2021. An arXiv link sits above it.
Two authors, one conference, one year. So the academic record of this project is a single paper from 2021, while the software has moved through a 0.7 line in 2023 and a 0.8 line in 2025.
That gap is normal for a hardware project of this kind, where the paper describes the approach and the software has since become seven components with their own guides. It does mean the paper will not tell you what the current firmware expects, or what the playground interface looks like.
The title in the citation matches the heading of the readme, which is a small consistency worth noting: the project has kept its name and its framing since the paper.
The community list points at the earlier version it descends from
There is a section of community projects, described as a small selection from a lot of them, with images linking out.
Four are linked. One is a 3D printing design on a hardware sharing site, which reads as a printable version of the vehicle body. One is a blog post about an improved version of an earlier OpenBot, on a site devoted to hobby robotics. One is a write-up of a Raspberry Pi robot car controlled by a smartphone, on a build site. And one is a video.
The second one is the informative link, because it names an earlier version from another organisation rather than an OpenBot release. The projects section is therefore partly a lineage: the project presented itself as a reimplementation, and the community list reflects that by including what came before.
The Raspberry Pi entry is the interesting practical one, because it suggests people have substituted different hardware for the Arduino and kept the phone as the brain, which is the arrangement the getting-started steps describe.
None of these are documented or supported. They are links, not integrations, so what you build from them is your own problem.
Editorial conclusion
OpenBot is worth reading if you have a phone and want to see what it can do as a robot's computer, because the split between an Arduino body and a phone brain is the whole idea and the project documents both halves. Four things to know before you build. The first documented step is reading the disclaimer, and it exists in five languages, so read the one that applies to where you are. The body is a real vehicle build with its own guide, so this is a hardware project with a software component rather than the reverse. The recorded primary language is Swift and there is an iOS directory, but the described product is the Android app, so read the Android guide. And the last release predates the last push by about eighteen months, with the newest tag from March 2025, so pin a tag and expect to read the component guides rather than a unified manual.
Frequently asked questions
what is openbot
It uses smartphones as the brains for low-cost robots. The project designed a small electric vehicle costing about $50 to serve as the robot body, and its Android software stack is described as supporting workloads such as person following and real-time autonomous navigation.
how to install openbot
Get the source as a zip archive or clone it from GitHub, forking first if you plan to contribute. Then follow the seven component guides in order: read the disclaimer, build a robot body, flash the Arduino firmware, install the Android apps, set up the controller, use the playground, and train a driving policy.
clawdbot vs openbot
The repository names no project in that comparison. What it describes is a specific pairing: an Arduino-based vehicle with a smartphone mounted on it running the applications, with the phone providing the vision and the Arduino providing the control.
openbot alternative
Nothing in the readme lists alternatives. It links instead to community projects built with it, including a printable body design, a documented improvement to an earlier version of the project, and a Raspberry Pi robot car controlled by a smartphone.
Is a robot a bot?
That question is about terminology rather than about this project. What OpenBot describes is a phone mounted on a small electric vehicle, with Arduino firmware on the vehicle and Android applications on the phone.
How do I create a bot?
The repository does not describe creating a chat bot. Its seven starting points are hardware and robotics: a robot body, Arduino firmware, Android apps, a controller, a programming playground, and a driving policy you can train.
Official sources
Add this badge to your README
If you maintain this project, the badge below links readers to this analysis and shows its maintenance status from the daily GitHub snapshot. Paste the markdown into your README; add ?metric=license or ?metric=stars to the image URL for a different field.
[](https://hysenlabs.com/projects/ob-f-openbot)Star history chart for your README
[](https://hysenlabs.com/projects/ob-f-openbot)Was this useful?