open5gs: a C codebase for 5G Core and the LTE EPC, documented off-site
Open5GS is a C-language Open Source implementation for 5G Core and EPC, i.e. the core network of LTE/NR network (Release-19)
At a glance
- What is it?
- Open5GS implements the 5G Core and the LTE EPC in C, with the latest release tagged for Release-19. Its README is a landing page rather than a manual: no install command, no build step, just a link to the documentation site, a sponsor page and three support addresses.
- Who is it for?
- open5gs suits someone who needs to read, build or run 5G Core and EPC code instead of buying a commercial core, and the repository already carries the packaging to do it. Three things to settle before starting.
- Can I use it commercially?
- Yes, with strict conditions. AGPL-3.0 is a network copyleft licence: if people use a modified version over a network, for example as a hosted service, you must offer them its source code under the same licence.
- Is it still maintained?
- Yes. The repository received new commits within the last day.
- What is it written in?
- Mainly C, according to GitHub's language statistics.
Answers come from the project's GitHub data, last synced on November 15, 2026, and from our analysis. They are not legal advice.
Star history
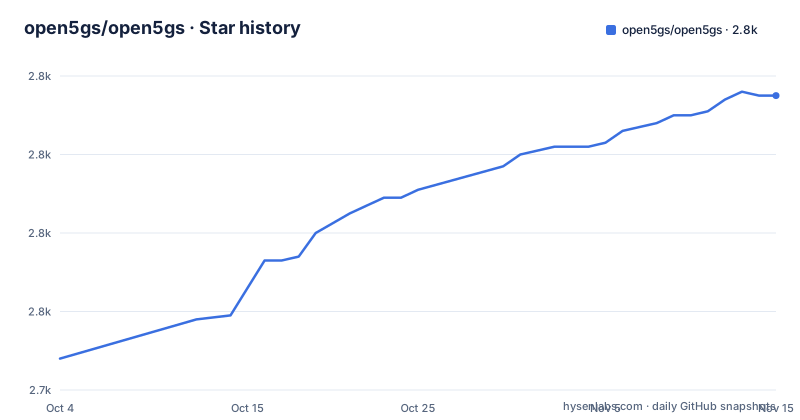
- open5gs/open5gs2,815 ★ · +67
| Repository | 2026-10-04 | 2026-11-15 |
|---|---|---|
| open5gs/open5gs | 2.7k | 2.8k |
67 Stars in the last 42 days, measured from the daily GitHub snapshot. Compare with other projects
Editorial analysis
Getting Started is one sentence and a link
The entire setup section reads as a pointer: follow the documentation at open5gs.org, with the docs themselves under open5gs.org/open5gs/docs/. There is no install command anywhere on the page, no package name, no build invocation and no minimum dependency list. So the first real question for anyone arriving here is where the instructions actually are, and the honest answer is off this repository. What the page does establish is where the project intends you to go and who maintains the destination. Everything else has to come from the documentation site, and for a C project of this size the build inputs are visible in the tree even when the commands are not. Nothing on the page suggests a quick start exists anywhere else, and no wrapper script or container definition is pointed at from the text.
Meson sits at the root next to a subprojects directory
The build system is visible in three filenames. `meson.build` is the root build definition and `meson_options.txt` sits beside it as the option file where a project like this exposes its feature switches, which is where you would look to find out whether a feature is compiled in or left out. The third is `subprojects/`, a directory Meson can use for fallback dependencies and wrap files. Its presence alone does not establish that every dependency is vendored or that configure and build work without network access; inspect the specific subprojects and wraps. Two analysis and formatting files sit alongside them, `.clang-tidy` for static analysis and `.editorconfig` for whitespace. The primary language is C, and there is no Python or shell entry point in the tree to suggest an alternative way in.
docker/, vagrant/, debian/ and webui/ are all in the tree
Four directories describe four ways of running or shipping the same core network, and none of them is explained on the landing page. `docker/` holds container definitions, `vagrant/` holds a local virtual machine environment, `debian/` holds Debian packaging including the control files and install layout, and `webui/` holds a browser interface. `configs/` sits next to them, which is where the sample configuration belongs, and `tests/` is a top-level sibling of `src/` rather than a nested test directory. `docs/`, `misc/`, `lib/` and `src/` complete the set. Read together, the names say the project expects you to pick a deployment shape before you touch configuration, and that a management surface exists as a component in its own right rather than as an add-on. What none of these directory names tell you is which one the project considers current.
AGPL-3.0 for the files, commercial terms from one vendor
The licensing section is the most substantive paragraph on the page. The open source files are made available under the GNU Affero General Public License version 3.0, and separately, commercial licenses are available from NewPlane, with a sales address given for that purpose. Technical support and customized services are offered by the same company at a support address. So this is a dual arrangement in which the default terms are the strongest copyleft in common use, and any organisation that needs different terms is routed to one named counterparty. The AGPL choice has a specific consequence for network equipment that the page does not discuss: it reaches beyond distribution of the binaries to network use, which is exactly the scenario a 5G core runs in. Whether that matters for a given deployment is a legal question, not a technical one, and the commercial route is the documented answer to it.
Release-19 shipped as v2.8.0 in June, and the branch moved on in September
The release list lines up with the specification the project targets. The newest tag is v2.8.0, published 20 June 2026 and titled with Release-19, matching the Release-19 named in the project's own summary. Before it sit v2.7.7 from 15 March 2026 and v2.7.6 from 19 July 2025, and neither of those two carries a specification number in its title. The gap between v2.7.6 and v2.7.7 is eight months, while v2.7.7 to v2.8.0 took three, which reads as a long stabilisation period followed by a feature release rather than a steady monthly cadence. The branch itself was last pushed on 23 September 2026, about three months after v2.8.0 appeared, and the repository is not archived. So the code on main and the code in the newest tag are not the same code, and the tags do not carry names that say which specification they implement without reading the release title.
Issues, discussions and chat are three separate doors
The community section splits support into three destinations with stated purposes. Bugs go to GitHub issues in this repository, other topics go to GitHub discussions, and voice and text chat live in a Discord workspace reached through an invite link. That split is the ordinary one for a project of this size and it tells you something about where a question is expected to land: a defect report belongs in issues, a design or usage discussion belongs in discussions, and anything conversational belongs in chat. Funding is a fourth door, since sponsoring is offered through OpenCollective and the page says the reason is to manage funding transactions transparently. Contributors arriving through a pull request are pointed at the Contributor License Agreement in advance, which is a separate step from the code of conduct and sits at its own address under the project domain.
One repository covers the 5G Core and the LTE EPC
The project's own summary states the scope plainly: a C-language open source implementation for 5G Core and EPC, that is the core network of an LTE or NR network, at Release-19. Both networks are in scope for the same codebase, which is the single most useful fact for anyone deciding whether this is the project they need. A laboratory that wants the LTE EPC side and the 5G Core side running in one environment does not have to reconcile two implementations, and the same applies to a test rig moving between generations. The C choice is stated as well, which places the project among native network daemons rather than among the higher-level tooling around them. Everything else about scope, from which network functions are implemented to which interfaces are supported, is left to the documentation site rather than to this page.
Editorial conclusion
open5gs suits someone who needs to read, build or run 5G Core and EPC code instead of buying a commercial core, and the repository already carries the packaging to do it. Three things to settle before starting. Where the instructions live, because the README is a landing page and the build detail is in the documentation site, the meson files and the shipped configs rather than in the repository text. What the licensing shape costs you, since the files are AGPL-3.0 and anything commercial comes from one named vendor. And which version you build, since Release-19 arrived in v2.8.0 in June 2026 and the branch has been pushed on since. Support and closed terms are both routed to that vendor, so an organisation that cannot use AGPL should start there rather than reading further into the tree.
Frequently asked questions
how to install open5gs
The README carries no install command. It sends you to the documentation at open5gs.org/open5gs/docs/, and the repository itself carries the options: a `docker/` directory, a `vagrant/` environment, `debian/` packaging and a `meson.build` with `meson_options.txt` at the root.
how to use open5gs
Usage is documented on the site the README points at rather than in the repository. The tree indicates the shapes it supports, with `configs/` for sample configuration, a `webui/` directory for a browser interface, `tests/` beside `src/`, and `docs/` alongside both.
how to install open5gs on ubuntu
No per-distribution steps appear in the README, which points only at the documentation site. What the tree carries for that route is a `debian/` directory holding the packaging, alongside the root `meson.build`, `meson_options.txt` and `subprojects/` for building the C sources.
how to setup open5gs
There is no setup section with commands on the landing page, only a link to open5gs.org/open5gs/docs/. Configuration for a run belongs in the shipped `configs/` directory, and build options live in `meson_options.txt` next to the root `meson.build`.
Official sources
Add this badge to your README
If you maintain this project, the badge below links readers to this analysis and shows its maintenance status from the daily GitHub snapshot. Paste the markdown into your README; add ?metric=license or ?metric=stars to the image URL for a different field.
[](https://hysenlabs.com/projects/open5gs-open5gs)Star history chart for your README
[](https://hysenlabs.com/projects/open5gs-open5gs)Was this useful?