OpenRocket: simulate before you build, and export when you want a second opinion
Model-rocketry aerodynamics and trajectory simulation software
At a glance
- What is it?
- A Java model rocket simulator whose default branch is called unstable and whose newest release is date tagged. Beyond the simulation itself, the interesting parts are the export paths, the network behaviour you can switch off, and the surrounding ecosystem.
- Who is it for?
- Use OpenRocket when you design model rockets and want to see the flight before cutting anything, especially if you iterate on motors or staging and want plots rather than guesses. It earns its place through interoperability: it exports to RockSim and RASAero II, writes OBJ for 3D printing and SVG for laser cutting, and has Python bridges for scripting.
- Can I use it commercially?
- Check first. The repository uses a licence we do not classify automatically, so read its LICENSE file before any commercial use.
- Is it still maintained?
- Yes. The repository received new commits within the last day.
- What is it written in?
- Mainly Java, according to GitHub's language statistics.
Answers come from the project's GitHub data, last synced on November 15, 2026, and from our analysis. They are not legal advice.
Star history
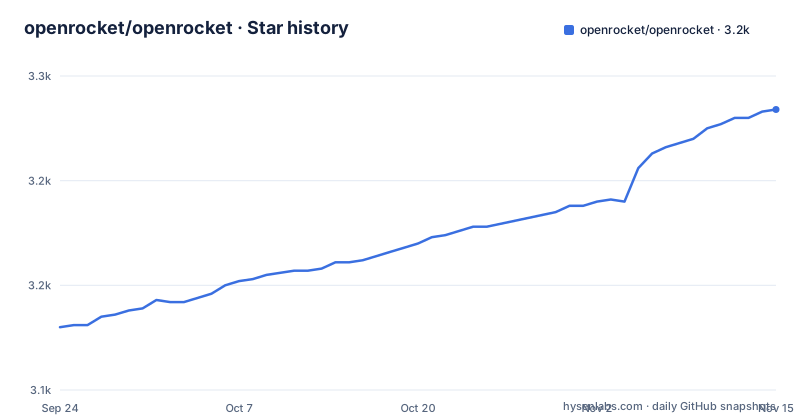
- openrocket/openrocket3,234 ★ · +104
| Repository | 2026-09-24 | 2026-11-15 |
|---|---|---|
| openrocket/openrocket | 3.1k | 3.2k |
104 Stars in the last 52 days, measured from the daily GitHub snapshot. Compare with other projects
Editorial analysis
Design, simulate, then decide to build
OpenRocket is a free, fully featured model rocket simulator, and its purpose is stated in one line: you design and simulate your rocket before actually building and flying it.
The simulation is described as six degree of freedom, which is the claim to hold on to, and the surrounding feature list is what a designer actually touches. There is automatic design optimization, a realtime display of simulated altitude, velocity and acceleration, and support for staging and clustering, so multi stage and clustered designs are first class rather than bolted on. The component library is broad enough for scale models, detailed decals, pods and unusual fin shapes, and there is a gallery in the documentation plus a video of a Vortikon rotating.
It is a Java application, and cross platform operation is on the feature list rather than something left implicit. That also explains the integration surface: scripting projects reach it through JPype rather than through a native API.
Export is where interoperability lives
Two export targets are named for other simulation programs: RockSim and RASAero II. For anyone who does not want to trust one simulator alone, that is the practical escape hatch, and the project keeps RockSim in the conversation rather than pretending to replace it.
Then there is export for making things. Components export to OBJ, which is what you want for 3D printing, and to SVG, which is what you want for laser cutting fins and plates. A rocket design is therefore not trapped inside the application: the geometry comes out in formats your cutter or printer already reads.
The file format is part of the tree as well, with a `fileformat.txt` at the top level describing it, and the ecosystem table lists a Python project that converts `.ork` files into RocketPy compatible formats. Between the OBJ and SVG exports and that converter, a design can move from simulation to manufacturing to another simulation stack without a manual redraw.
Installers come from the website, the Snap is listed separately
The install path is deliberately plain: the installers are on the project's own downloads page at openrocket.info, and release notes live on each release's page as well as on a release notes page on the website. There is no package manager instruction in the README, which for a Java desktop application is reasonable.
Two packaging systems are nevertheless visible in the repository. The tree has an `install4j/` directory, which is the installer builder used to produce those downloads, and a `snap/` directory, matching the Snapcraft badge at the top of the README. A Maven Central badge points at the `info.openrocket/core` artifact, so the core is also published to a Java repository rather than existing only inside the desktop application.
The practical implication is that there is more than one artefact to choose from, and they are not guaranteed to be the same build. Check the version on whichever one you install.
No telemetry, and the network can be switched off
One paragraph in the README answers the question people rarely ask about desktop simulation software, so it is worth quoting the substance rather than the sentiment. OpenRocket states that it does not collect telemetry and does not upload rocket designs.
It does list the network requests it makes, and they are all user facing: checking for application updates, checking for motor database updates, opening online resources you asked for, and submitting a bug report when you request it. Nothing is described as background reporting.
The last sentence is the one to act on. Internet access can be disabled in the application preferences, which turns the update checks and the online resource fetches into a deliberate choice rather than a background fact. If you are modelling a design you do not want leaving the machine, that switch is the mechanism, and the motor database is the part you will notice losing first.
The default branch is called unstable
The default branch for this repository is named `unstable`, which tells you how the project treats its own trunk, and the release names are date based rather than semantic: `release-24.12.beta.01`, then `release-24.12.RC.01`, then `release-24.12`.
The gaps in that sequence are informative. The beta was published 2024-12-20, the release candidate 2025-03-25, and the final 24.12 on 2025-07-27, so the release candidate sat for four months before the final tag. The last commit in this snapshot is dated 2026-10-03, which means the published line has been unchanged for more than a year while development continued.
For a simulator that people use as a design tool, that split is normal and manageable: pick a release if you want a known state, or follow the branch if you want the fixes. What it does mean is that bug fixes are not arriving under a tag you can point a user at.
Translated docs, and two directories that look alike
Documentation lives on ReadTheDocs, and the README links a getting started page inside it, but the orientation advice is more useful than the link: open one of the in program example designs and work from there, adjusting component dimensions, plotting a simulation and swapping motors.
The translation setup is visible in the tree. A `crowdin.yml` sits at the top level next to a Crowdin badge, so the documentation is translated through that service rather than by hand, and `.readthedocs.yaml` is what builds the site. Two directories that look similar, `doc/` and `docs/`, both exist at the top level, which is the kind of duplication that makes it worth checking which one a change belongs in.
The project also keeps more release paperwork than most: a `ChangeLog`, a `ReleaseNotes.md`, a `releasing.txt` describing how a release is cut, and a `CITATION.cff` for people who cite the software in work. `AGENTS.md`, `CONTRIBUTING.md`, `SUPPORT.md` and `CODE_OF_CONDUCT.md` complete the set.
An ecosystem list where one plugin is already archived
The README maintains a catalogue of related projects in five groups, and reading it tells you what the software does not do itself.
Core projects are the simulator, the Jekyll website source, and a separate parts catalogue repository that was originally somebody else's database. Integration and scripting is the largest group: a Python module that drives OpenRocket through JPype and was forked from SilentSys's version, a converter from `.ork` files to RocketPy formats, scripts for six degree of freedom landing scatter visualisation, a Quality Diversity optimization tool, and a Java Monte Carlo wrapper.
Engine and aerodynamics extensions cover a Python liquid engine generator and ORBrake, a Java plugin for active drag control with air brakes, which is explicitly marked archived. Wind and atmospheric data come from ORWind for multi level wind and from Aloft for weather profiles of wind, temperature and pressure. Design and CAD work is where the FreeCAD rocket workbench sits.
One archived plugin in a list of active ones is a fair signal: check each project's own state before you build on it.
Editorial conclusion
Use OpenRocket when you design model rockets and want to see the flight before cutting anything, especially if you iterate on motors or staging and want plots rather than guesses. It earns its place through interoperability: it exports to RockSim and RASAero II, writes OBJ for 3D printing and SVG for laser cutting, and has Python bridges for scripting. Leave it if you need a maintained release cadence on a date stamped version, because the newest tag is 24.12 from July 2025 while work continues on a branch named unstable. Before you trust a simulation, plot it and check the motor database entry yourself, and if you care about network behaviour, read the preference that disables internet access so you know exactly which checks stop.
Frequently asked questions
What is OpenRocket software?
A free, fully featured model rocket simulator written in Java. You design and simulate a rocket in it before building and flying it, with six degree of freedom flight simulation, staging and clustering support, and plots of the results.
what is openrocket used for
Designing and simulating model rockets before building them, including scale models, pods, staging and unusual fin shapes. It also exports designs, so components can go to OBJ for 3D printing or SVG for laser cutting.
how to install openrocket
Installers are published on the project downloads page at openrocket.info, with release notes on each release's page and on the website. A Snap is also listed on Snapcraft, and the repository carries install4j and snap directories for those builds.
is openrocket free
It is described as a free, fully featured model rocket simulator. It also states that it collects no telemetry and uploads no rocket designs, and that internet access can be disabled in the application preferences.
is openrocket open source
The README carries a GNU GPL version 3 badge and the repository includes a LICENSE.TXT file. Note that the repository metadata reports no recognised licence identifier, so read the licence file itself rather than the badge.
How accurate is OpenRocket?
The project describes its simulation as six degree of freedom, but publishes no accuracy figures or comparisons against real flights in its README. Treat accuracy as something you verify against your own flight data and motor data.
Official sources
Add this badge to your README
If you maintain this project, the badge below links readers to this analysis and shows its maintenance status from the daily GitHub snapshot. Paste the markdown into your README; add ?metric=license or ?metric=stars to the image URL for a different field.
[](https://hysenlabs.com/projects/openrocket-openrocket)Star history chart for your README
[](https://hysenlabs.com/projects/openrocket-openrocket)Was this useful?