Point Cloud Library: the modules are in the tree, the answers are on the site
Point Cloud Library (PCL)
At a glance
- What is it?
- Point Cloud Library is a BSD licensed C++ project for 2D and 3D image and point cloud processing whose source tree is organised as one directory per algorithm family. What it does not carry is documentation: compiling, API reference, and support routing all point off the repository, and the previous website was compromised before being replaced.
- Who is it for?
- Use it if you are writing C++ that needs point cloud algorithms, you can commit to a platform-specific build, and you are willing to read documentation that tracks master rather than the release you installed. Avoid it if you need a pinned API reference, a subdirectory in examples/ for registration, tracking, visualization, or machine learning, or a documented single command that fetches and builds it.
- Can I use it commercially?
- Check first. The repository uses a licence we do not classify automatically, so read its LICENSE file before any commercial use.
- Is it still maintained?
- Yes. The repository last received commits 1 day ago.
- What is it written in?
- Mainly C++, according to GitHub's language statistics.
Answers come from the project's GitHub data, last synced on November 14, 2026, and from our analysis. They are not legal advice.
Star history
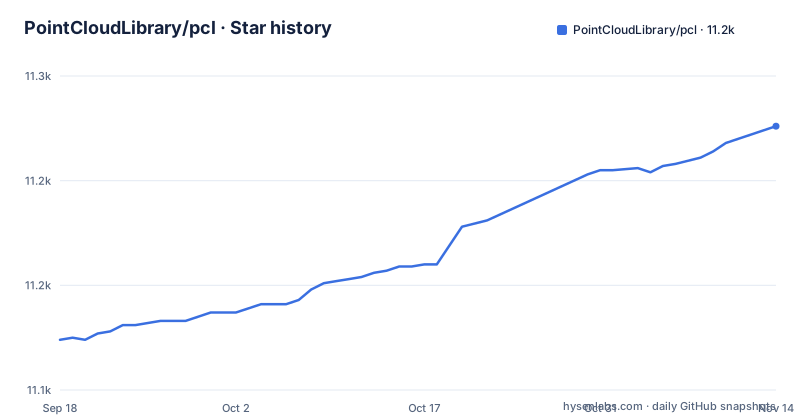
- PointCloudLibrary/pcl11,226 ★ · +102
| Repository | 2026-09-18 | 2026-11-14 |
|---|---|---|
| PointCloudLibrary/pcl | 11.1k | 11.2k |
102 Stars in the last 57 days, measured from the daily GitHub snapshot. Compare with other projects
Editorial analysis
Compiling means picking one of three platform tutorials
There is no install command in this project's README, and no package manager line either. What it offers is a choice of three links, one each for Linux, Mac OS X, and Microsoft Windows, all hosted as tutorials on pcl-tutorials.readthedocs.io. That structure has a cost. Every dependency, flag, and generator step for a given platform lives on that one page, so choosing the wrong page, or one written for a different compiler generation, is entirely on you to notice. Contributors are pointed at CONTRIBUTING.md for the workflow, and the issue tracker expects you to have read its bug reports section before you file anything.
Six CI jobs define the compiler matrix and its edges are sharp
The build status table lists one job per platform and compiler pair: Ubuntu 20.04 with GCC, Ubuntu 22.04 with Clang, Ubuntu 24.04 with GCC, Windows x86 built with VS2019, Windows x64 built with VS2022, and macOS Sonoma 14 and macOS Sequoia 15 with Clang. A separate Documentation job and a Read the Docs badge for the tutorials sit beside them, and the repository is not archived, with its last push landing on October 30, 2026. Read that matrix for what it leaves out: 22.04 is only exercised under Clang, the two Windows targets use two different Visual Studio generations, no Linux job is 32-bit, and the macOS rows name OS versions without naming an architecture. Code that builds on an ARM Mac or under MinGW sits outside what these badges promise.
Both documentation sets track master instead of a release tag
There are two documentation homes and neither is pinned to a release. The tutorials live on pcl-tutorials.readthedocs.io, and the Read the Docs badge points at the master build of them. The API reference lives at pointclouds.org/documentation/ and is called PCL trunk documentation, which means the documentation for unreleased master rather than for the 1.15.1 tag. The consequence is concrete in both directions: after installing a release you can be reading descriptions of functions that only exist on master, and worse, you can find a function documented for trunk that your installed release does not have. Nothing in the README states which release the current documentation corresponds to.
The previous website was compromised and only an archive copy remains
Documentation hosting has moved to https://pointclouds.org, and that site is open to contributions through its own repository, PointCloudLibrary.github.io. If you follow an older link that still points at the previous site, the instruction here is to use the copy captured by the internet archive on October 17, 2019, and it comes with a warning: that site was hacked before and could still be hosting malicious code. Practical reading for a user: treat anything executable that came from the archived copy as untrusted and prefer the current site. For a reader following citations, the other consequence is that older links now resolve to an archived page the project no longer stands behind.
The tree is one directory per algorithm family and examples cover only some
PCL's source layout is a directory per topic: 2d, apps, benchmarks, common, features, filters, geometry, gpu, io, kdtree, keypoints, ml, octree, outofcore, recognition, registration, sample_consensus, search, segmentation, simulation, stereo, surface, tools, tracking, and visualization, alongside the build files and doc/. The examples directory mirrors only part of that list, with subdirectories for common, features, filters, geometry, keypoints, outofcore, segmentation, stereo, and surface. Registration, tracking, visualization, ml, recognition, kdtree, octree, simulation, gpu, and cuda therefore ship as modules with no subdirectory in examples/, and for those areas the tutorials and trunk documentation are the references on offer.
Consumers depend on PCL through a generated CMake package config
The repository root carries CMakeLists.txt, a cmake/ directory, pcl_config.h.in for the generated header, and two templates named PCLConfig.cmake.in and PCLConfigVersion.cmake.in. Those two templates are the interface downstream projects use: they become a CMake package config and a version file, so your own build can locate PCL and state which version it needs. What the README does not tell you is which imported targets each module contributes. For packagers the consequence is sharper: a distribution package that relocates the install prefix has to get those generated files right, or nothing finds PCL at all.
Usage questions are pushed off the issue tracker on purpose
The README routes two kinds of conversation away from GitHub. Bugs go through the bug reports section of CONTRIBUTING.md, which it asks you to read before filing. Everything else, meaning how to use PCL, plus installation, debugging, and troubleshooting, is sent to a Stack Overflow tag named point-cloud-library or to the project's Discord server. The effect on a reader is real: a usage question posted as an issue is likely to be redirected, and your debugging notes end up on a public Q and A site instead of in the repository history where the next person hitting the same wall would look for them.
The only citation guidance points at a 2011 paper
For researchers the README asks you to cite PCL if you use it or use it as a baseline, and it supplies one bibliography entry for Rusu and Cousins, titled 3D is here: Point Cloud Library (PCL), published at ICRA in Shanghai in May 2011. That entry names no release and no component, while the current line is 1.15.1, tagged on August 26, 2025, after 1.15.0 from February 2025. If your evaluation reports numbers on a recent release, the entry the project hands you does not identify it.
Editorial conclusion
Use it if you are writing C++ that needs point cloud algorithms, you can commit to a platform-specific build, and you are willing to read documentation that tracks master rather than the release you installed. Avoid it if you need a pinned API reference, a subdirectory in examples/ for registration, tracking, visualization, or machine learning, or a documented single command that fetches and builds it. Before starting, check that your compiler pair appears in the build status table, read the platform tutorial for your own system rather than a neighbour's, take dependencies from your distribution rather than from the archived website copy, and confirm which release the documentation you are reading actually describes.
Frequently asked questions
Is the Point Cloud Library free to use?
The README states that PCL is released under the terms of the BSD license and is therefore free for commercial and research use, and it is funded by a consortium of commercial companies plus the Open Perception non-profit. It says nothing about the cost of the sensors or data that produce point clouds.
What does point cloud registration mean in PCL?
The README does not define the term. What the repository shows is a dedicated registration/ module next to sample_consensus/, kdtree/, and search/, with no matching subdirectory in examples/, so the API documentation on pointclouds.org/documentation/ is the reference the project points you to.
What does LiDAR point cloud mean for PCL users?
No part of the README mentions LiDAR, and no sensor specific layer is named in the source tree. PCL describes itself as a library for 2D and 3D image and point cloud processing, with io/, kdtree/, and octree/ among the modules it ships.
What is point cloud used for in Point Cloud Library?
The README describes PCL as a standalone, large scale, open project for 2D and 3D image and point cloud processing without listing application areas. The closest thing to a task list is the module layout itself, covering filters, features, keypoints, segmentation, surface, and outofcore work.
Official sources
Add this badge to your README
If you maintain this project, the badge below links readers to this analysis and shows its maintenance status from the daily GitHub snapshot. Paste the markdown into your README; add ?metric=license or ?metric=stars to the image URL for a different field.
[](https://hysenlabs.com/projects/pointcloudlibrary-pcl)Star history chart for your README
[](https://hysenlabs.com/projects/pointcloudlibrary-pcl)Was this useful?