AmazingHand: eight servos inside a printed hand, and the disclaimer that comes with it
Code and model to control the AH!
At a glance
- What is it?
- Pollen Robotics' AmazingHand puts eight Feetech SCS0009 servos into four printable fingers for a 400 g hand. The mechanism and the CAD are open; the accuracy of a printed copy is not.
- Who is it for?
- AmazingHand is a mechanism and a parts library first: what it offers is the parallel finger linkage, an openly readable Onshape document and mirrored CAD, not a finished gripper. Anyone printing it should treat the disclaimer as a build step, because printed copies miss the theoretical angles and long prehensile tasks are untested, which leaves the feedback the SCS0009 exposes as the only guardrail until that software exists.
- Can I use it commercially?
- Yes. Apache-2.0 is a permissive licence: you can use, modify and sell software built on it, as long as you keep its copyright and licence notices.
- Is it still maintained?
- Activity is slowing. The repository last received commits 6 months ago.
- What is it written in?
- Mainly Python, according to GitHub's language statistics.
Answers come from the project's GitHub data, last synced on November 15, 2026, and from our analysis. They are not legal advice.
Star history
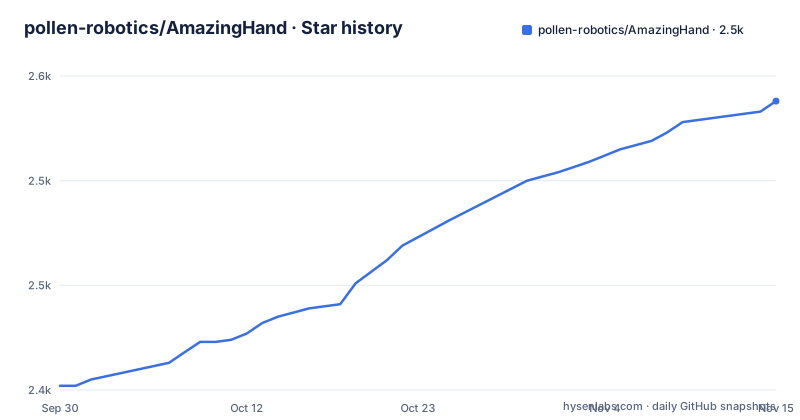
- pollen-robotics/AmazingHand2,538 ★ · +136
| Repository | 2026-09-30 | 2026-11-15 |
|---|---|---|
| pollen-robotics/AmazingHand | 2.4k | 2.5k |
136 Stars in the last 46 days, measured from the daily GitHub snapshot. Compare with other projects
Editorial analysis
Two SCS0009 servos per finger, one parallel mechanism
Each finger is moved by a parallel mechanism, and each finger carries two small Feetech SCS0009 servos: one for flexion and extension, one for abduction and adduction. Four fingers at two servos each is the eight actuators the design keeps inside the shell, which is why no cable crosses the wrist. A finger is built from two phalanges articulated together, the shells are described as flexible almost everywhere, the printed hand weighs 400 g, and the stated cost is under 200 EUR. The wrist interface is drawn around Reachy2's wrist, which the project calls Orbita 3D, with a note that it can be adapted to another robot's wrist. Which servos and which fasteners go in depends on a bill of materials that lives in a shared spreadsheet, linked twice from the same page: once for components and once for the custom printed parts.
Two control paths, and a calibration script per finger
The hand can be driven two ways, and the choice decides what you build. The serial route is a bus driver from Waveshare plus a Python script. The other route is an Arduino plus a Feetech TTL Linker, which sits between the board and the bus. Either way calibration is not optional: a small script has to be run against each finger, and the repository keeps one calibration program per route, one under PythonExample and one under ArduinoExample. Basic demos exist for both, named AmazingHand_Demo.py and AmazingHand_Demo.ino. Beyond that sits the Demo directory, which holds inverse and forward kinematics examples along with tools for testing and configuring the motors. The top level is small enough to read in one screen: ArduinoExample, Demo, LICENSE, PythonExample, README.md, assets, cad and docs.
The eight actuators need an external 5 V supply
Running the hand means supplying power it does not carry. An external power supply is needed to power the eight actuators inside the hand, and the README names the part it expects: a DC/DC adapter that converts 220V to 5V / 2A and ends in a jack connector. That is a mains-side adapter rather than a USB lead, so the bench needs a socket as well as the serial connection that the chosen control route requires. On the Arduino route the same current still has to reach the servos with the TTL Linker in the chain. A 3D printing guide and an assembly guide sit in the docs directory as PDFs, both named for the hand, and the bill of materials spreadsheet is where the electrical choices are actually pinned down rather than either PDF.
The two demo file names point at each other's directory
The basic demo section has its two links crossed. The Python script AmazingHand_Demo.py is linked to the ArduinoExample directory, and the Arduino program AmazingHand_Demo.ino is linked to the PythonExample directory. The calibration section higher up does not repeat the swap: there the Python and Waveshare pairing points at PythonExample and the Arduino and TTLinker pairing points at ArduinoExample. Read literally, the demo section sends each file to the folder that holds the other flavour. The same passage also embeds a bare attachment URL with no caption, so nothing on the page says which of the two runs it shows. Nothing else repeats those two file names, which makes the crossed anchors the first thing to check before wiring anything.
Two hands on one bus need different IDs, not a different order
Building a left hand next to a right one collides on the serial bus, and the fix has two halves. The first is mechanical and stays fixed: keep the same assembly order for the servos. The second is addressing, and it has to change, because two different servos on one serial bus cannot carry the same ID. The instruction is to keep the assembly order but set IDs different from the right hand values. Software is needed as well, since each hand has to be driven independently, and the demo that runs the same patterns on both at once exists only in Python, named AmazingHand_Demo_Both. No Arduino equivalent is named on the page, which leaves the dual hand case resting on the Python side. The Demo directory carries matching configurations for the same problem: dataflow_tracking_real.yml and dataflow_tracking_real_2hands.yml beside their simulation variants.
The disclaimer admits printed parts miss the theoretical angles
The accuracy problem is stated by the project itself, and its list of causes is specific. Angles measured on real prototypes differ from the theoretical angles for flexion, extension, abduction and adduction. The attributed causes are imperfect 3D printed parts, balljoint rods adjusted by hand one at a time, reworked servo horns, and the flexibility of the plastic. The same passage says the design has not been tested for long and complex prehensile tasks, and that a kind of smart software has to be built before objects can be grasped safely, meaning without damaging servos or mechanical parts. The servo is the part able to report trouble: the SCS0009 offers torque enable and disable, torque feedback, a current position sensor and heat temperature feedback, plus an unlisted remainder the page marks with an ellipsis.
Left hand parts are mirrored, and the guide covers only the right
The printed parts come in two flavours and the naming says which is which. Fingers are the same on both sides, some parts are symmetrical, specific right hand parts are prefixed with an R and the left hand parts with an L. The assembly guide that pairs with the bill of materials is written for a standalone right hand, so a left hand is not covered by it end to end. The documented workaround is narrower than that sounds: keep the same IDs for the servo locations and select right or left in the software. That choice happens in code rather than in the CAD, which leaves the mirrored STL and STEP files under cad as the only place the geometry differs. The Onshape document is open to everyone, and predefined positions in its named position tooling carry the servo angles that match them.
Apache 2.0 for code, CC BY 4.0 for the printed parts
Licensing is split rather than uniform, and the split follows the physical parts. The code is offered under Apache 2.0, while the mechanical design is under a Creative Commons Attribution 4.0 International License, with the badge printed above the project title. Repository metadata records Apache-2.0 as the single licence, which covers the code half only. A second licence file also exists: the top level carries LICENSE, and Demo carries its own LICENSE next to its Cargo.toml and README.md. Demo is therefore a crate with its own configuration, containing AHControl, AHSimulation and HandTracking directories plus four YAML files named for angle simulation, tracking on real hardware, tracking with two hands, and tracking in simulation. Which terms reach the printed hand depends on reading both files.
Editorial conclusion
AmazingHand is a mechanism and a parts library first: what it offers is the parallel finger linkage, an openly readable Onshape document and mirrored CAD, not a finished gripper. Anyone printing it should treat the disclaimer as a build step, because printed copies miss the theoretical angles and long prehensile tasks are untested, which leaves the feedback the SCS0009 exposes as the only guardrail until that software exists. Dual-hand builds should plan on the Python route from the start, because the both-hands demo exists only there. Before ordering anything, confirm the licence split between the Apache 2.0 code and the CC BY 4.0 mechanical design, and check what the crossed demo links actually resolve to in the tree.
Frequently asked questions
How many servos does one AmazingHand finger use?
Two small Feetech SCS0009 servos per finger, one for flexion and extension and one for abduction and adduction, with four fingers in all.
What does the AmazingHand repository contain?
Top level entries are ArduinoExample, Demo, LICENSE, PythonExample, README.md, assets, cad and docs. Demo adds AHControl, AHSimulation, HandTracking, a Cargo.toml and four dataflow YAML files.
Can two AmazingHand hands share one serial bus?
Only with different servo IDs per hand, while keeping the same assembly order. The both-hands demo named AmazingHand_Demo_Both is Python only.
Which licence applies to an AmazingHand build?
The code is under Apache 2.0 and the mechanical design is under Creative Commons Attribution 4.0. Demo also carries its own LICENSE file next to the root one.
Does the AmazingHand disclaimer cover long grasping tasks?
It says the design has not been tested for long and complex prehensile tasks, and that smart software has to be built before objects can be grasped safely.
Official sources
Add this badge to your README
If you maintain this project, the badge below links readers to this analysis and shows its maintenance status from the daily GitHub snapshot. Paste the markdown into your README; add ?metric=license or ?metric=stars to the image URL for a different field.
[](https://hysenlabs.com/projects/pollen-robotics-amazinghand)Star history chart for your README
[](https://hysenlabs.com/projects/pollen-robotics-amazinghand)Was this useful?