Simbody's install section says six ways and numbers eight, and its sample stops mid-statement
High-performance C++ multibody dynamics/physics library for simulating articulated biomechanical and mechanical systems like vehicles, robots, and the human skeleton.
At a glance
- What is it?
- A C++ multibody dynamics library in generalized coordinates, used by OpenSim, Gazebo and MacroMoleculeBuilder. It is an API rather than an application, the example code in the readme ends inside a constructor call, and the newest tag is Simbody-3.8 from May 2025.
- Who is it for?
- Take it if you need an articulated mechanism solver with forward, inverse and mixed dynamics, contact models and error controlled integrators, and you are writing the application around it, because the project is explicit that it ships an API and not a program. Read the examples directory before the user guide: filenames like DzhanibekovEffect, BricardMechanism and ExampleKneeJoint describe the range faster than the feature list does.
- Can I use it commercially?
- Yes. Apache-2.0 is a permissive licence: you can use, modify and sell software built on it, as long as you keep its copyright and licence notices.
- Is it still maintained?
- Yes. The repository last received commits 9 days ago.
- What is it written in?
- Mainly C++, according to GitHub's language statistics.
Answers come from the project's GitHub data, last synced on November 15, 2026, and from our analysis. They are not legal advice.
Star history
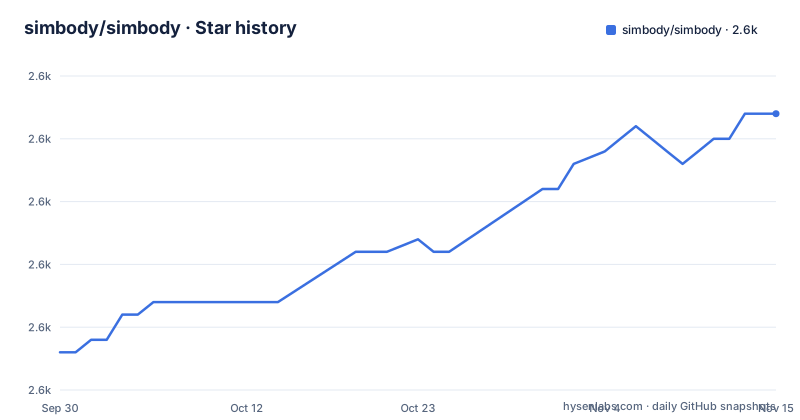
- simbody/simbody2,572 ★ · +19
| Repository | 2026-09-30 | 2026-11-15 |
|---|---|---|
| simbody/simbody | 2.6k | 2.6k |
19 Stars in the last 46 days, measured from the daily GitHub snapshot. Compare with other projects
Editorial analysis
The install section says six ways and then numbers eight
One sentence introduces the installation chapter: the file provides instructions for 6 different ways of installing Simbody. The numbered list under it runs to eight. Windows built from source with Visual Studio, Linux or Mac built from source with gcc or Clang and make, Mac through Homebrew, Ubuntu and Debian through apt-get, FreeBSD through pkg, Windows through MinGW, conda, and vcpkg. The sentence after the list widens it further, saying these are not the only ways and offering CMake with Xcode on a Mac as another. Linux users are pointed at Repology to see whether their distribution packages it, which is a ninth route again.
The double pendulum example ends inside a constructor call
The code sample is the shortest path into the API, and it opens like this:
#include "Simbody.h"
using namespace SimTK;
int main() {
    // Define the system.
    MultibodySystem system;
    SimbodyMatterSubsystem matter(system);
    GeneralForceSubsystem forces(system);
    Force::Gravity gravity(forces, matter, -YAxis, 9.8);
What follows builds a rigid body with mass properties of one unit, zero centre and unit inertia, adds a sphere decoration of radius 0.1, and then opens a mobilized body call: MobilizedBody::Pin pendulum1 on matter.Ground() with a transform at the origin. The argument list ends on a comma and the block closes there, before the second link of the two-link chain exists. The image and the step by step version of the same example are elsewhere in the file, one of them in the user guide.
The compiler list stops at Visual Studio 2019 while the build asks for CMake 3.21
The dependency chapter asks for CMake 3.21 or later, LAPACK 3.6.0 or later with BLAS, and a compiler from a list running Visual Studio 2015, 2017 or 2019 on Windows, gcc 4.9.0 or later, Clang 3.4 or later, or Apple Clang from Xcode 8 or later. FreeGLUT with Xi and Xmu is optional and so is Doxygen, where the floor is 1.8.6 with a recommendation of at least 1.8.8, while the Windows steps ask for 1.8.8 or higher outright. Two Windows details are worth knowing: Visual Studio 2015 does not include C++ support unless you pick a custom install and the Visual C++ component, and any other C++ code you pair with Simbody has to be compiled with the same compiler.
It is a library, not an application, and the file says so early
The second paragraph settles what the project is: Simbody provides a C++ API used to build domain specific applications, and it is not a standalone application itself. What it provides is a multibody dynamics library that models motion in generalized or internal coordinates in O(n) time, which the file notes is sometimes called a Featherstone-style physics engine. The named users are OpenSim for biomechanics, Gazebo for robotics and MacroMoleculeBuilder for biomolecular work, and the file shows an RNA simulation of several molecules containing thousands of bodies, performed with MMB by Samuel Flores. Everything else in the repository is aimed at the same audience: the theory manual, the advanced programming guide and the user guide, with the project homepage on simtk.org rather than on the documentation host.
The manuals are raw PDF links against the master branch
Two of the reading links fetch files straight out of the repository: the theory manual and the advanced programming guide, both addressed as raw paths under Simbody/doc/ on the master branch, which is also the default branch here, so those links track whatever is on master. The API documentation is somewhere else entirely, on simbody.github.io, and support runs through the Simbody Forum on simtk.org, while bugs and feature requests go to GitHub issues. For a first project the file points at one file rather than a guide, cmake/SampleCMakeLists.txt, as the starting point for wiring Simbody into your own CMake build. The tree carries a doc/ directory at the root as well, so there are two places named for documentation.
The examples directory is the widest catalogue of what the library does
The listed examples read like an index of capabilities. There is a BricardMechanism directory, a closed topology mechanism, a cable path and a cable span, a knee joint, IMU tracking, gears, a geodesic example, a custom constraint, an event handler and an event reporter, an assembler playground, an inverse kinematics problem, constrained optimization and a numerical differentiation variant of it, and a family of motor examples split into constraint, controller and motion variants. DzhanibekovEffect.cpp sits among them, which is the tennis racket theorem rather than a joint. The list is alphabetical and it is cut off partway through the motor family, so the directory is both the catalogue and the place the file is least complete.
Forward, inverse and mixed dynamics with three optimizers and two contact models
The feature list is short and specific. Joint, constraint and force types come in a wide variety and are meant to be extended by the user. Dynamics run forward, inverse or mixed, with motion driven either by forces or by prescribed motion. Contact is available in the Hertz and Hunt and Crossley models. Three optimizer families are named: gradient descent, interior point, and a global method built on CMA. A variety of numerical integrators come with error control. Visualization is an OpenGL visualizer, which is what the optional FreeGLUT, Xi and Xmu dependencies exist for. Below that list sits a second list of six things a reader might want, from installing the library and using it in their own program to viewing API documentation, learning the theory, extending it, getting support at the forum and reporting a bug.
Three releases, and the newest is five years after the one before
The tags are Simbody-3.6.1 from 2018-06-12, Simbody-3.7 from 2019-12-08 and Simbody-3.8 from 2025-05-17. That is eighteen months between the first two and more than five years between the last two. The names do not carry a v prefix, and the download instructions reflect a manual process: look for the highest numbered release, click the .zip button and unzip it, with the assumed path C:/Simbody-source, or clone the repository instead. The branch was last pushed 2026-10-01, so work continues on the branch while the published gap grows, and a user who installs the packaged version and a user who tracks master are a long way apart. CHANGELOG.md sits at the root beside CMakeLists.txt, CMakePresets.json and .clang-format, next to three SimTK era source directories named SimTKcommon, SimTKmath and Simbody.
Editorial conclusion
Take it if you need an articulated mechanism solver with forward, inverse and mixed dynamics, contact models and error controlled integrators, and you are writing the application around it, because the project is explicit that it ships an API and not a program. Read the examples directory before the user guide: filenames like DzhanibekovEffect, BricardMechanism and ExampleKneeJoint describe the range faster than the feature list does. Plan the toolchain against the stated floors, CMake 3.21 and LAPACK 3.6, and remember the release cadence is irregular, since 3.8 landed more than five years after 3.7 while the branch kept moving.
Frequently asked questions
What is Simbody used for?
It is a C++ multibody dynamics library for articulated mechanisms, modelling motion in generalized coordinates in O(n) time, which the project calls a Featherstone-style engine. It is an API for building applications rather than a program you run.
Which projects use Simbody?
OpenSim for biomechanics, Gazebo for robotics and MacroMoleculeBuilder for biomolecular research. A simulation of several RNA molecules containing thousands of bodies was performed with MMB by Samuel Flores.
How do I install Simbody?
Eight routes are numbered: source build with Visual Studio on Windows, source build with gcc or Clang and make on Linux or Mac, Homebrew on Mac, apt-get on Ubuntu or Debian, pkg on FreeBSD, MinGW on Windows, conda and vcpkg. Linux users are also pointed at Repology.
What does Simbody need to build?
CMake 3.21 or later, LAPACK 3.6.0 or later with BLAS, and a compiler from a list covering Visual Studio 2015, 2017 or 2019, gcc 4.9.0 or later, Clang 3.4 or later and Apple Clang 8 or later. Doxygen and FreeGLUT with Xi and Xmu are optional.
Where is the Simbody API documentation?
At simbody.github.io. The theory manual and the advanced programming guide are linked as PDF files fetched from the master branch of the repository, and support runs through the Simbody Forum on simtk.org.
What is the newest Simbody release?
Simbody-3.8, published 2025-05-17. Before it came Simbody-3.7 on 2019-12-08 and Simbody-3.6.1 on 2018-06-12, so more than five years separate the last two tags.
Official sources
Add this badge to your README
If you maintain this project, the badge below links readers to this analysis and shows its maintenance status from the daily GitHub snapshot. Paste the markdown into your README; add ?metric=license or ?metric=stars to the image URL for a different field.
[](https://hysenlabs.com/projects/simbody-simbody)Star history chart for your README
[](https://hysenlabs.com/projects/simbody-simbody)Was this useful?