octomap: three components in the tree, two in the README, and a license that splits by subfolder
An Efficient Probabilistic 3D Mapping Framework Based on Octrees. Contains the main OctoMap library, the viewer octovis, and dynamicEDT3D.
At a glance
- What is it?
- A probabilistic 3D mapping framework built on octrees, with a visualisation library under a different license and a third component the README never names. The build recipes also disagree with each other about which directory they run in.
- Who is it for?
- Judgment: OctoMap is the right shape for occupancy mapping when you want a probabilistic octree you can query and update yourself, and the separation between the library and the viewer is a genuine design decision rather than an accident. Three things to settle first.
- Can I use it commercially?
- Not without permission. GitHub finds no licence file in the repository, and without a licence all rights are reserved by default: you may read the code but not reuse it. Check the README, or ask the authors, before using it.
- Is it still maintained?
- Yes. The repository last received commits 50 days ago.
- What is it written in?
- Mainly C++, according to GitHub's language statistics.
Answers come from the project's GitHub data, last synced on November 15, 2026, and from our analysis. They are not legal advice.
Star history
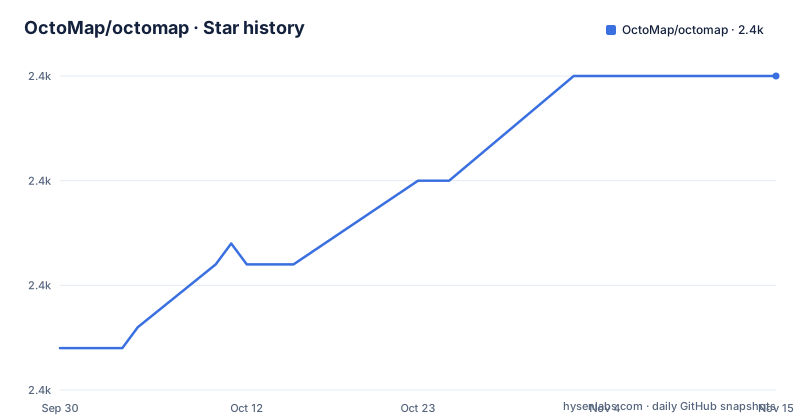
- OctoMap/octomap2,400 ★ · +13
| Repository | 2026-09-30 | 2026-11-15 |
|---|---|---|
| OctoMap/octomap | 2.4k | 2.4k |
13 Stars in the last 46 days, measured from the daily GitHub snapshot. Compare with other projects
Editorial analysis
The overview says two libraries while the tree holds three directories
The overview section is explicit: OctoMap consists of two separate libraries each in its own subfolder, `octomap` for the library itself and `octovis` for visualisation. The top-level listing shows three directories of source, not two: `dynamicEDT3D/` sits beside `octomap/` and `octovis/`, alongside a `scripts/` directory and one `CMakeLists.txt`.
The project description on the repository agrees with the tree rather than with the overview, naming the main library, the viewer, and dynamicEDT3D as the three things it contains.
So a reader working from the README alone will build two of the three and never learn that the third exists. That matters for the license question below, and for anyone who assumed `octomap/` was the only source in the checkout.
The two build recipes create and expect different build directories
Building only the library is a five line sequence:
cd octomap
mkdir build
cd build
cmake ..
make
Building the complete package is three lines, and the first of them is `cd build`. Nothing in that recipe creates it. The line above it in the README says you can build each library separately with CMake by running it from the subdirectories, or build both together from this top-level directory, so the second recipe assumes a `build` directory at the top level that the first recipe never creates there. The first one creates it inside `octomap/`.
The output statement runs into the same problem. Binaries and libraries are said to end up in `bin` and `lib` of the top-level directory where you started the build, and following the library-only recipe means you started in the `octomap` subdirectory, so they land under `octomap/bin` and `octomap/lib` rather than at the repository root.
Installing OctoMap through vcpkg
OctoMap documents a vcpkg installation route. The following commands use a Unix-style shell; for Windows Command Prompt or PowerShell, use `bootstrap-vcpkg.bat` and the Windows vcpkg executable instead:
git clone https://github.com/Microsoft/vcpkg.git
cd vcpkg
./bootstrap-vcpkg.sh
./vcpkg integrate install
./vcpkg install octomap
What follows is the part worth pausing on. The octomap port in vcpkg is kept up to date by Microsoft team members and community contributors, and if the version is out of date the instruction is to open an issue or pull request on the vcpkg repository, not on this one.
So the path most Windows users will take is maintained somewhere else, and a stale package version is not this repository's problem to fix. The same paragraph also notes that details for compiling, especially under Windows, live in the two per-library readme files rather than at the top level.
The library is BSD, the viewer is GPL, and the field says nothing
The license is set out per subfolder rather than once for the repository. The library itself is under the New BSD License, in `octomap/LICENSE.txt`. The viewer and related libraries are under the GPL, in `octovis/LICENSE.txt`.
The repository's own license metadata is empty, which means nothing is asserted about the project as a whole at the level you would read on a package index. The split above is stated in the README and is the accurate description of the two named components.
The gap is the third directory. `dynamicEDT3D/` is in the tree and in the project description, and it is covered by neither of those two statements. If your build links it, you are relying on terms that this repository does not spell out.
v1.10.0 shipped in March 2024 and v1.10.1 in September 2026
The three most recent tags are v1.9.6 on 23 January 2021, v1.10.0 on 19 March 2024, and v1.10.1 on 18 September 2026. The gaps between them are three years and two months, then two years and six months, and the last one is a patch release on a two year old minor line.
The default branch is `devel`, not main or master, and it was pushed on 26 September 2026, eight days after the tag. So the branch moves on a timescale of days while the tags move on a timescale of years, and a clone gives you the branch rather than the tag.
For a library with 704 forks and 41 open issues, that cadence is the thing to plan around rather than the star count. Pin the tag if you need the behaviour the releases describe, and read `octomap/CHANGELOG.txt` for what actually changed between them.
Copyright is dated 2009-2014, the site is plain http, the badge is Travis
The attribution block reads: originally developed by Kai M. Wurm and Armin Hornung at the University of Freiburg, copyright 2009-2014, currently maintained by Armin Hornung, with further authors in `octomap/AUTHORS.txt`. The copyright range stops more than a decade before the most recent tag, which is normal for a header that was never updated rather than a sign of anything.
Maintenance is named as one person. That is worth knowing when you are deciding whether a bug report will be read.
The addresses are less tidy. The project homepage at the top of the file is plain http, while the API documentation link below it is https. The build status badge points at travis-ci.org even though the repository's automation lives under `.github/`. And the contributor and changelog files are reached through the `octomap/` subfolder, so the visualisation library has no equivalents named at the top level.
ROS gets two wiki pages and the promise of pre-compiled packages
For anyone working inside ROS, the README stops building and starts redirecting. Two separate wiki pages are offered, one for OctoMap and one for OctoVis, and the file says pre-compiled packages are available there rather than telling you to compile anything.
That is the shortest path in the whole file, and it also means the two libraries are packaged and documented as two things even inside the ecosystem, which is consistent with the license split and inconsistent with the single top-level build recipe.
The top-level file also hands off twice more: compilation details live in `octomap/README.md` and `octovis/README.md`, and the changes are tracked in `octomap/CHANGELOG.txt`. What remains here is the overview, the licenses, the vcpkg route and a build status badge, which is a small file for a project with three source directories.
Editorial conclusion
Judgment: OctoMap is the right shape for occupancy mapping when you want a probabilistic octree you can query and update yourself, and the separation between the library and the viewer is a genuine design decision rather than an accident. Three things to settle first. Decide which component you are licensing, because the library and the viewer are under different terms and the repository metadata names neither. Read the two build recipes as two separate procedures rather than one sequence, because the second one assumes a directory the first one never creates at that level. And if you are on Windows, plan to track the vcpkg port rather than this repository, since that is where its maintainers say problems with the version should be reported.
Frequently asked questions
what is octomap
OctoMap is an efficient probabilistic 3D mapping framework based on octrees. The repository holds the octomap library itself, the octovis visualisation libraries and tools, and a dynamicEDT3D component. It is written in C++, and the library and the viewer are built as separate projects in their own subfolders.
how to install octomap
From source, build with CMake. For the library alone, run `cd octomap`, `mkdir build`, `cd build`, `cmake ..` and `make`. Binaries and libraries land in the `bin` and `lib` directories of wherever you started the build. For Windows, `vcpkg install octomap` is the documented route, and that port is maintained in the vcpkg repository rather than here.
how to use octomap
The repository ships two libraries you build separately, octomap and octovis, and each has its own readme with the details. If you use ROS there are pre-compiled packages, pointed at from the octomap and octovis wiki pages, and the API documentation is published separately at the octomap documentation site.
what is octomap in ros
Inside ROS, OctoMap is available as pre-compiled packages rather than something you compile. The project points at two wiki pages, one for OctoMap and one for OctoVis, and notes that those packages are available, so the ROS route bypasses the CMake build described in the repository.
octomap alternatives
The repository names no alternatives to itself. What it does name is a packaging route, with pre-compiled packages for ROS through the octomap and octovis wiki pages, and a vcpkg port maintained by Microsoft team members and community contributors that is tracked on the vcpkg repository rather than here.
Official sources
Add this badge to your README
If you maintain this project, the badge below links readers to this analysis and shows its maintenance status from the daily GitHub snapshot. Paste the markdown into your README; add ?metric=license or ?metric=stars to the image URL for a different field.
[](https://hysenlabs.com/projects/octomap-octomap)Star history chart for your README
[](https://hysenlabs.com/projects/octomap-octomap)Was this useful?