Missing dependencies vanish silently, the Python wheel skips Windows, and the test line stops mid-word
Pangolin is a lightweight portable rapid development library for managing OpenGL display / interaction and abstracting video input.
At a glance
- What is it?
- Pangolin is a C++ library for OpenGL windowing, video input and interactive debugging across four platforms, built with CMake and split into components you can include piecemeal. The file is unusually candid about its own rough edges: everything except cmake is optional and silently dropped, the Python packaging targets do not work on Windows, and two sections break off mid-sentence.
- Who is it for?
- Pangolin suits a computer vision or robotics developer who wants a display and a plot window without hand-writing per-platform code, and it does not suit anyone who expects a configure step to tell them what they got.
- Can I use it commercially?
- Yes. MIT is a permissive licence: you can use, modify and sell software built on it, as long as you keep its copyright and licence notices.
- Is it still maintained?
- Yes. The repository last received commits 20 days ago.
- What is it written in?
- Mainly C++, according to GitHub's language statistics.
Answers come from the project's GitHub data, last synced on November 15, 2026, and from our analysis. They are not legal advice.
Star history
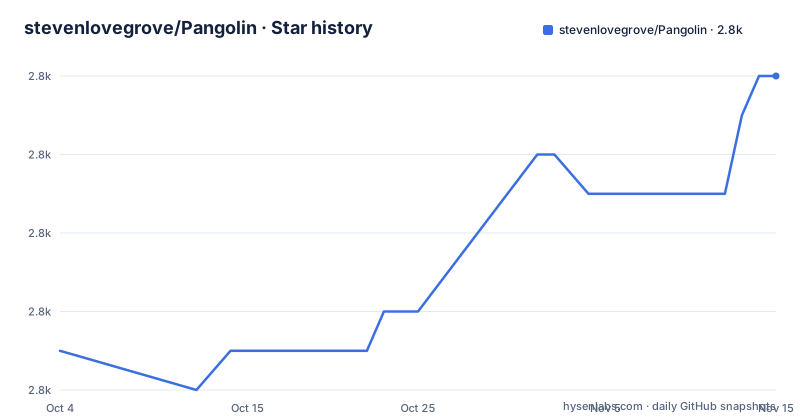
- stevenlovegrove/Pangolin2,758 ★ · +7
| Repository | 2026-10-04 | 2026-11-15 |
|---|---|---|
| stevenlovegrove/Pangolin | 2.8k | 2.8k |
7 Stars in the last 42 days, measured from the daily GitHub snapshot. Compare with other projects
Editorial analysis
A missing dependency produces a successful build with the feature gone
The dependency section sets out the policy plainly. Most dependencies are optional, and the file says Pangolin does it's best to build something with what it gets, so dependencies which are not found will be silently ignored. The only way to find out what you actually got is to read the output of the configure stage and look for the Found and Enabled lines. Everything else about the build is designed to keep going: the components are split so you can include just what you need, and the listed dependency categories, build system, windowing system, rendering, video and image loading, and wrappers or cross compilers, are all offered as things the library will use if present. The escape hatch for the other direction is a BUILD_PANGOLIN_(option) variable you set to false through a cmake configuration tool such as ccmake or cmake-gui when an optional dependency is causing trouble.
The Python wheel and install targets do not work on Windows
The feature list opens by promising builds for Windows, Linux, OSX and the web through Emscripten, and the Windows section recommends a native Visual Studio 2019 toolchain while ruling out mingw and WSL as unsupported. The Python section then draws a line under part of that. Its note says the python wheel and install targets are only currently working on MacOS and Linux, that on Windows you are out of luck right now, and asks for help. Three targets are involved: pypangolin_wheel to build the wheel, and pypangolin_pip_install and pypangolin_pip_uninstall to install and remove it. The build recipe also runs the install target directly with `cmake --build build -t pypangolin_pip_install`, while the Python section asks you to build the wheel first and install it afterwards, so the two descriptions of the same step do not match either.
The test instruction in the build block ends inside its own sentence
The shell block for building the library walks through cloning, installing prerequisites, configuring with `cmake -B build` and building with `cmake --build build`, with a Ninja variant that adds -GNinja and a note about installing ninja-build. Its last line is a comment asking for tests and naming Catch2 as the requirement, and that line stops partway through the word it needs: it ends at which must be m. There is no closing line and no follow-up sentence telling you what Catch2 must match or which target runs the suite. Catch2 also appears nowhere in the dependency categories the file enumerates, so the only place the test prerequisite is discoverable is that unfinished comment. The example inventory gives the rest of the picture, from HelloPangolin and HelloPangolinOffscreen through HelloPangolinThreads and SharedMemoryCamera to SimplePlot, SimpleVideo, SimpleRecord and VBODisplay.
One script picks the package manager and cmake is the only hard requirement
Rather than enforcing a package manager, the project ships a script that generates the package list for whichever one you have, across apt, port, brew, dnf, pacman and vcpkg. You can ask what is recommended before installing anything, and you can override the manager choice:
# See what package manager and packages are recommended
./scripts/install_prerequisites.sh --dry-run recommended

# Override the package manager choice and install all packages
./scripts/install_prerequisites.sh -m brew all
Three levels exist, required, recommended and all, and across the whole enumerated set only one package is marked required: cmake. Everything else, from the windowing system to the video and image libraries, is a recommendation. Combined with the silent-ignore policy, a machine with nothing but a compiler and cmake installed configures cleanly and links a library with no window, no renderer and no video path. The Windows notes add a second assumption to the same story: the snippets on the page are bash, and the file recommends gitbash for executing them and for cloning the repository, while the native toolchain itself is expected to be Visual Studio 2019 rather than mingw or WSL.
Components are the unit of inclusion and tags move every few months
The library is described as split into a few components so you can include just what you need, and the repository carries a matching components/ directory beside cmake/, tools/, scripts/ and examples/. Most of the feature surface sits there: cross platform windowing with off-screen buffers as one implementation option, viewport management with 3D navigation handlers and utilities for computer vision and robotics camera and coordinate conventions, video input and output wrappers for ordinary and machine-vision cameras with a flexible filter interface for post-processing channels and formats, tweak variables with one-line definitions and extensible types, and a drop-down Quake-like console that is extensible for different shells but currently supports a Python live console. The video side is where the optional dependency list spreads widest: DC1394 for FireWire machine-vision cameras, ffmpeg, jpeg and png, plus the separate OpenGL and GLES rendering entries. The interactive debugging suite is the part the file argues for hardest, naming 3D manipulation, plotters, tweak variables and the console as tools for python scripting and live tweaking, and noting that there are 101 widgeting libraries and several tweak variable libraries already, with Pangolin offering another implementation with a few pros and cons. The three most recent tags are v0.9.6 on 2026-08-19, v0.9.5 on 2026-04-10 and v0.9.4 on 2025-10-08.
Two sections send you to a cmake step the build recipe never runs
The build recipe configures with `cmake -B build`. Elsewhere the file twice refers to a different invocation. The silent-ignore paragraph tells you to check the output of the `cmake ..` stage for the Found and Enabled lines, and the Python section says the chosen interpreter is reported during the `cmake ..` step, then shows how to override it with `cmake -DPython3_EXECUTABLE=/path/to/python ..`, or with the same flag fed from a which python3 lookup. Those two forms both write into the current directory rather than the build directory the recipe created, and the two alternatives in that sentence are separated with no space at all between them. It is a small thing, but it is the difference between inspecting the configure log you just produced and reconfiguring somewhere else. The same care is asked for on the interpreter side: you have to be careful about what python version Pangolin found and is attempting to link against, and it reports that during the configure step. Overriding it means pointing the cmake variable at an executable, either a literal path or the output of a which python3 lookup, which is how you choose between an interpreter inside a virtualenv and the one on your path.
The web target is announced three times and explained in text that is not there
The web appears first in the feature list, where building for the web is paired with Emscripten, and again in the examples section, which points at an online gallery and three examples you can run in a browser: SimplePlot, SimpleDisplay and SimpleMultiDisplay. Then a short On the Web section says to see the Emscripten compile for web section below. That section is not in the readable text, which stops earlier in the runtime problems discussion, so the anchor it names has no visible destination in this file. What is left is the dependency entry for Emscripten under wrappers and cross compilers, alongside Python3 and pybind, which is the only place the toolchain is named outside that missing section. The documentation strategy itself is worth noting: the file says Pangolin is mostly documented through its simple examples, which live in an examples/ directory with a PythonExamples/ subdirectory for the Python versions, so the reference material a new user actually reads is source code rather than prose.
The one runtime error explained in the file is cut off at its first remedy
A Common Runtime Problems section exists, and it explains one message. Framebuffer with requested attributes not available is attributed to building against an old or unaccelerated OpenGL version. The first suggested response begins with either your graphics d and stops there, so the remedy is not readable. That leaves the Windows guidance as the only other troubleshooting in the file: build natively with the Visual Studio 2019 build tools, treat mingw and WSL as unsupported, and use gitbash for the snippets on the page. The root also holds a file named LICENCE rather than LICENSE, a package.xml for ROS packaging that the file never mentions, a .clang-format, and the .gitmodules that explains why every clone instruction uses the recursive flag.
Editorial conclusion
Pangolin suits a computer vision or robotics developer who wants a display and a plot window without hand-writing per-platform code, and it does not suit anyone who expects a configure step to tell them what they got. Check the Found and Enabled lines in the configure output before you trust a feature, keep to the macOS and Linux path if you need the Python module, and remember that master is called a development branch in the project's own words while tagged builds move every few months. Disable unwanted components explicitly rather than assuming absence was detected.
Frequently asked questions
How does Pangolin handle a dependency it cannot find?
It ignores it. The README says dependencies which are not found will be silently ignored, and the way to find out what was actually enabled is to read the configure output and look for the Found and Enabled lines. cmake is the only package marked required.
Does the Pangolin Python module work on Windows?
Not currently. The README states the python wheel and install targets are only working on MacOS and Linux, and says that on Windows you are out of luck right now. The targets involved are pypangolin_wheel, pypangolin_pip_install and pypangolin_pip_uninstall.
Which platforms can Pangolin be built for?
Windows, Linux, OSX and the web through Emscripten. On Windows the file recommends building natively with the Build Tools for Visual Studio 2019 and says mingw and WSL are unsupported.
How do you install the dependencies Pangolin needs?
With the bundled script, which generates packages for apt, port, brew, dnf, pacman or vcpkg. Use --dry-run recommended to see the list first, and pass -m with a manager name plus a level, for example -m brew all, to install.
Should I build Pangolin from master or from a tag?
The file states that master is a development branch and that issues and pull requests should be raised against it, then suggests choosing a stable tag if you prefer. The three most recent tags are v0.9.6, v0.9.5 and v0.9.4.
Official sources
Add this badge to your README
If you maintain this project, the badge below links readers to this analysis and shows its maintenance status from the daily GitHub snapshot. Paste the markdown into your README; add ?metric=license or ?metric=stars to the image URL for a different field.
[](https://hysenlabs.com/projects/stevenlovegrove-pangolin)Star history chart for your README
[](https://hysenlabs.com/projects/stevenlovegrove-pangolin)Was this useful?