thp/psmoveapi: reading the PS Move without a PS3, and the build switches that decide what you get
Cross-platform library for 6DoF tracking of the PS Move Motion Controller. Sensor fusion, computer vision, ambient display (LED orb).
At a glance
- What is it?
- PS Move API is a C library that talks to Sony Move controllers over USB and Bluetooth on Linux, macOS and Windows, with camera based 3D tracking for up to five units. Commits still reach master, but the last tagged release is 4.0.12 from December 2020, and the README carries no install command at all.
- Who is it for?
- PS Move API is the right library if you need to read Sony PS Move controllers from Linux, macOS or Windows with no PS3 in the loop, and you are willing to drive the camera tracker yourself. It is the wrong choice if you need a packaged install command, a current tagged release, or a compiled Python extension, since the last tagged build is 4.0.12 from 19 December 2020 and the README has no install line to copy.
- Can I use it commercially?
- Check first. The repository uses a licence we do not classify automatically, so read its LICENSE file before any commercial use.
- Is it still maintained?
- Yes. The repository last received commits 102 days ago.
- What is it written in?
- Mainly C, according to GitHub's language statistics.
Answers come from the project's GitHub data, last synced on November 15, 2026, and from our analysis. They are not legal advice.
Star history
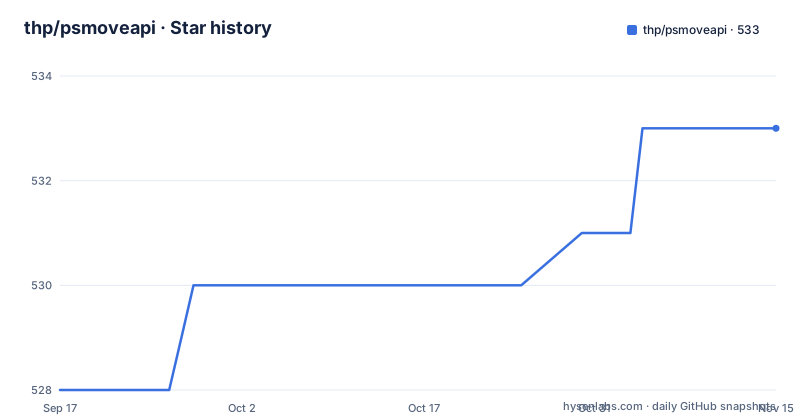
- thp/psmoveapi533 ★ · +5
| Repository | 2026-09-17 | 2026-11-15 |
|---|---|---|
| thp/psmoveapi | 528 | 533 |
5 Stars in the last 59 days, measured from the daily GitHub snapshot. Compare with other projects
Editorial analysis
Bluetooth pairing happens over USB, not over the air
Pairing is the step that surprises people, and PS Move API puts it in USB on purpose. A controller is paired to the host machine through a USB cable, and from then on the same unit answers over Bluetooth for sensor reads and over either transport for the LED colour and the rumble motor. The core feature list separates those paths deliberately: inertial sensors and buttons arrive over Bluetooth, while LEDs and rumble can be driven over USB or Bluetooth.
That split is what lets a program keep working after the cable comes out, because orientation and button state do not depend on the wire being present. Extension devices sit on the same footing as the controller itself, with the Sharp Shooter and the Racing Wheel named as the supported cases. The same list puts the limit at up to 5 controllers tracked in 3D space via OpenCV, which is a camera and fusion limit rather than a Bluetooth one. Five controllers also means five separate USB pairing passes, one per unit, before tracking begins.
The README describes no timeout, no retry count and no reconnect path, so treat recovery behavior as something you have to observe on the hardware you own rather than something you can read off a guarantee.
Orientation comes from the AHRS filter, position comes from a camera
The library splits pose into two problems with two different sources. Orientation is computed by an open source AHRS algorithm, which is why 3D orientation tracking works with no camera in the loop at all. Position cannot be derived that way, so tracking in 3D space needs a camera: a PS Eye on Linux, Windows and macOS, or any other suitable camera source, with OpenCV doing the video work.
Sensor fusion is the layer that joins the two, and it is the part the maintainer has written up in depth in a master's thesis hosted on thp.io, a document that also carries the third party license analysis on pages 51 to 53. The repository description frames the same capability as 6DoF tracking for the PS Move Motion Controller, with sensor fusion and computer vision named as the two halves and an ambient LED orb as the visible output. The 2012 Google Summer of Code participation is where that work was done. Changes since then are recorded in the CHANGELOG.md at the top of the tree.
PSMOVE_USE_PS3EYE_DRIVER is off unless you turn it on
One CMake option deserves reading before you build anything on macOS. PS3EYEDriver is the dependency that interfaces with the PSEye camera on macOS, it is used only inside the tracker, and its CMake switch PSMOVE_USE_PS3EYE_DRIVER is disabled by default. The dependency itself is released under the MIT license with parts based on GPL code, and it is the single stated exception to the general rule that all dependencies are under an MIT or BSD style license.
Default off is the sensible default for a library that most callers only want as a controller reader, because the GPL derived parts never enter the link. Turning it on changes the licensing picture of the build you produce, and CMake gives a hint about library licensing for your current configuration at configure time, so you can read the answer off the configure output instead of guessing at it. The tracker on macOS is the only path that reaches this code, so a Linux or Windows build driven by a different camera source never loads it.
CMake options decide which external modules get compiled
Third party code lives under external/ and is wired in through .gitmodules, so a fresh clone is not the whole build. Each module there may carry a different license, and compiling them is optional rather than implied: CMake options configure which features you need, and the tree keeps the reusable pieces in cmake/ with the sources in src/ and the public surface in include/.
That optionality cuts both ways. It keeps a default configuration small and its license set predictable, and it also means a build that misses a module can leave you with a tracker that compiles cleanly and then reports nothing on screen, with no documented error string to match against. The configure time licensing hint is the part worth heeding, because it reflects the options you actually passed rather than the options someone assumed.
The prose documentation is built from this tree rather than hosted elsewhere: the repository carries a .readthedocs.yaml and a docs/ directory that feed psmoveapi.readthedocs.io.
COPYING says Simplified BSD while the license field reads NOASSERTION
The license story has a wrinkle that only shows up if you check two places. The COPYING file and the README both state that the source is released under the terms of a Simplified BSD style license, with the exact license text in COPYING. The license field in the repository metadata reads NOASSERTION, which is what GitHub shows when it cannot map the file to a license it recognizes. Neither statement corrects the other, and there is no second license file here, so the text in COPYING is the operative one and the metadata field adds nothing.
The dependencies are the part that actually changes obligations. In general all of them are under an MIT or BSD style license, and exactly one exception is named: PS3EYEDriver, released under the MIT license with parts based on GPL code. Two places carry the detail, external/README inside the source tree and pages 51 to 53 of the maintainer's thesis.
Python arrives through ctypes, C and C++ come first
The language story is short and honest about priority. The core library is written in C, with portability and performance given as the reasons, and additional C++ headers exist for easier interoperability. On top of that sits ctypes-based bindings for Python 3, which means the Python surface loads the built library through the standard library's ctypes module rather than through a compiled extension of its own.
The examples directory shows the three shapes side by side: examples/c/ for the native path, examples/labs/ as a second and more experimental group, and examples/python/ for the bindings, with examples/CMakeLists.txt tying them into the same build. The fastest way to see the intended shape of a call is to read those three directories rather than to guess from the library name, because the ctypes layer and the C header layer do not present the same ergonomics.
bindings/ sits at the top level next to src/ and include/, so the bindings are part of this repository rather than a downstream package you would install separately.
The README carries no install command, the docs carry the build
Here is the practical gap to plan around: the README has no fenced install or build command anywhere in it, and no package manager line either. There is nothing to copy out of that file, so any tutorial showing one is filling the gap from elsewhere. The tree holds what you need to build from source yourself, with CMakeLists.txt at the top level, cmake/ for the module system, external/ for third party code, and the docs/ directory that feeds psmoveapi.readthedocs.io.
Because the build is driven by CMake options, the build documentation is a list of switches rather than a single command line, and configure time is where licensing for your configuration gets reported. A GitHub Actions workflow is wired in too, referenced by the badge at the top of the README, which gives you a continuous integration path to compare a local configure output against.
For version history before building, CHANGELOG.md is in the tree. For the reasoning behind the fusion code, the master's thesis linked from the README is the longer read.
Commits landed on master in August 2026, releases stopped in 2020
Two dates describe the maintenance state and they point in different directions. The last push to the default branch master is dated 5 August 2026, so commits are still arriving. The newest release is 4.0.12, published on 19 December 2020, preceded by 4.0.11 on 25 September 2020 and 4.0.10 on 3 May 2020. That is roughly five years and eight months between the last tagged release and the last commit, so a consumer pinning a tagged version is pinning 2020 code, while a consumer building from master is building code that no release has been cut against.
The activity numbers point the same way. The repository shows 530 stars and 173 forks, a little under a third of the star count, with 22 open issues alongside them. It is not archived, the project website is thp.io/2010/psmove/, and the documentation is at psmoveapi.readthedocs.io.
Support comes in two shapes. Free community support runs through the PS Move Mailing List at [email protected], and professional support with custom development is offered on request. Patches go in as pull requests on GitHub, bug reports and feature requests go to the issue tracker, and the coding style section asks only that you stay consistent with the surrounding code.
Editorial conclusion
PS Move API is the right library if you need to read Sony PS Move controllers from Linux, macOS or Windows with no PS3 in the loop, and you are willing to drive the camera tracker yourself. It is the wrong choice if you need a packaged install command, a current tagged release, or a compiled Python extension, since the last tagged build is 4.0.12 from 19 December 2020 and the README has no install line to copy. Before you commit, check three things: whether the five controller ceiling and the AHRS orientation path cover what you are building, whether enabling PSMOVE_USE_PS3EYE_DRIVER on macOS changes your licensing obligations, and whether the external/ modules named in your configure output are the ones you expected.
Frequently asked questions
Is PS Move API still being worked on?
Commits are still landing: the last push to the default branch master is dated 5 August 2026. The newest tagged release is much older, 4.0.12 from 19 December 2020, so building from master and consuming a release give you very different code.
How many PS Move controllers can PS Move API track at once?
Up to 5 controllers in 3D space via OpenCV. That is a camera and sensor fusion limit rather than a Bluetooth one, and each controller is paired to the host over USB before tracking starts.
Do I need a PS3 console to use PS Move API?
No. The library reaches the Sony Move Motion Controller over Bluetooth and USB directly from your PC on Linux, macOS and Windows. For 3D position you also need a camera, either a PS Eye or another suitable source.
What license is PS Move API under?
The COPYING file and the README both name a Simplified BSD style license, while the repository's license field reads NOASSERTION. Dependencies are under MIT or BSD style licenses, with PS3EYEDriver the one exception: MIT licensed with parts based on GPL code, used only by the tracker on macOS and off by default.
Where do I find install instructions for PS Move API?
The README has no install command. Build from the source tree with CMakeLists.txt at the top level, pick which external/ modules to compile through CMake options, and read the guide at psmoveapi.readthedocs.io, which is built from the docs/ directory in this repository.
Official sources
Add this badge to your README
If you maintain this project, the badge below links readers to this analysis and shows its maintenance status from the daily GitHub snapshot. Paste the markdown into your README; add ?metric=license or ?metric=stars to the image URL for a different field.
[](https://hysenlabs.com/projects/thp-psmoveapi)Star history chart for your README
[](https://hysenlabs.com/projects/thp-psmoveapi)Was this useful?