The Unity Robotics Hub is now a five module course with a 2022 release tag
Central repository for tools, tutorials, resources, and documentation for robotics simulation in Unity.
At a glance
- What is it?
- The repository that was a hub of robotics tools now presents itself as a written companion to a video course about Simulation Pro, with five modules, a Unity project at its root and an ARCHIVE.md for the packages it no longer supports. Its newest release tag is from February 2022 while its last commit is from September 2026.
- Who is it for?
- Unity Robotics Hub is worth reading as a course rather than as a toolkit, and the two are no longer the same thing. The material assumes a Unity 6.3 project, a Simulation Pro install from the Package Manager, and for its last two modules a virtual machine running Ubuntu 26.04 with a specific ROS 2 distribution, which is a heavy floor for a five hour course and one that will age quickly.
- Can I use it commercially?
- Check first. The repository uses a licence we do not classify automatically, so read its LICENSE file before any commercial use.
- Is it still maintained?
- Yes. The repository last received commits 53 days ago.
- What is it written in?
- Mainly C#, according to GitHub's language statistics.
Answers come from the project's GitHub data, last synced on November 14, 2026, and from our analysis. They are not legal advice.
Star history
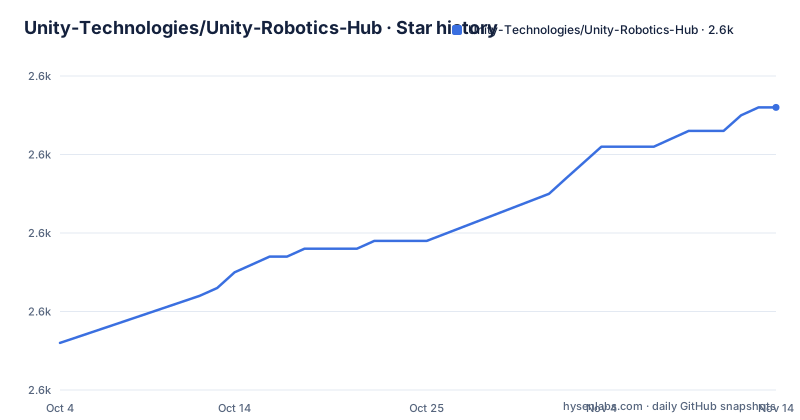
- Unity-Technologies/Unity-Robotics-Hub2,616 ★ · +30
| Repository | 2026-10-04 | 2026-11-14 |
|---|---|---|
| Unity-Technologies/Unity-Robotics-Hub | 2.6k | 2.6k |
30 Stars in the last 41 days, measured from the daily GitHub snapshot. Compare with other projects
Editorial analysis
The newest release tag is from 2022 while commits are from 2026
The release history stops four and a half years ago. The three published tags are v0.5.0 on 2021-07-16, v0.6.0 on 2021-10-04 and v0.7.0 on 2022-02-03, while the last push to the default branch is dated 2026-09-22. So the repository has been worked on continuously and has not been released since February 2022.
There is a structural reason as well as a slow one. The code in this repository is a Unity project rather than a distributed library: Assets, Packages and ProjectSettings sit at the root, so there is no artifact a release would publish in the usual sense. The package the page is actually about is installed through the Unity Package Manager and does not live here.
That leaves the tag list describing an era that has been superseded. The page itself acknowledges this by pointing at ARCHIVE.md for content on unsupported packages, which is where a reader looking for the robotics tooling that once made this repository famous is meant to go.
The body is a course, the description is still a tools hub
The repository description calls itself a central repository for tools, tutorials, resources and documentation for robotic simulation in Unity. The body of the page now reads very differently. The first section announces that the repository has been updated with Simulation Pro, described as Unity's latest robotics package, and states that it is supported for production on Unity 6.3 and newer, with early access open to Unity Industry developers.
The package is described through four capabilities: a URDF importer that gives a drag and drop experience for robot description files, sensor simulation covering Lidar, RGB-D and IMU out of the box, direct communication with ROS based hardware from Unity, and a headless Linux build target for parallel simulation across hardware.
The access path is the other half of the story. Learning more runs through a contact form whose link carries a campaign identifier and a sales reason, and the hands-on material is a five hour program on Unity Academy. What used to be an open repository is now the front page for a commercial package, and the description line is the last sentence still describing the old thing.
Five modules, and each one leaves a specific artifact behind
The written companion is organised as five module files, and the module table records what you are holding at the end of each one. That column is the most useful part of the table, because it turns the course into a checklist.
Module 1 imports a Panda arm from URDF and configures it for stable physics. Module 2 produces a publisher and a subscriber exchanging messages over something called a Dummy Connection, plus transform data broadcast for every joint on the arm. Module 3 covers the sensors the package ships: camera, fisheye, stereo depth, time of flight, three separate LiDAR implementations and IMU. Module 4 assembles a live simulation with simulation time, coordinate systems, a ROS Endpoint Connector and differential drive, ending with an rclpy node navigating the robot by LiDAR and odometry. Module 5 exports images, point clouds and CSV logs.
The page is explicit that the order matters, since each module builds on the project state left by the previous one. That is a linear course with no branches, so skipping ahead means reconstructing the project yourself.
The requirements pin three current releases at the same time
The requirements table is where the cost of this course becomes concrete. Unity 6.3 or newer is the floor, stated twice, once as the version supported for production. Simulation Pro comes through the Package Manager, and two sample packages are named: Simulation Pro Basic and Prebuilt LiDAR Sensors.
Then there are the course assets themselves, the Panda URDF, a material fixer script, an AMR prefab and ROS 2 test files, which tells you the project state you are expected to assemble before starting.
The heaviest line is the ROS 2 environment, required for modules 4 and 5 only, specified as Ubuntu 26.04 with ROS 2 Lyrical Luth running on a virtual machine. Setting up ROS 2 is declared out of scope and delegated to the ROS 2 wiki. So half the course assumes a machine configuration that the course explicitly will not help you build, pinned to three of the newest releases available, which is a combination that will need revisiting as each of them moves.
Assets, Packages and ProjectSettings make this a Unity project
The top level listing shows what kind of repository this is. Alongside the usual .github, .gitignore, .editorconfig and .pre-commit-config.yaml entries, there are three Unity project directories, Assets, Packages and ProjectSettings, a docs directory, a tutorials directory, and a solution file named for the course itself in the slnx format.
Then there are the leftovers of several generations of documentation. There are two image directories, images and imgs, which is one more than a project needs. There is example.csv sitting at the root, which appears to be the logging output from module 5 kept as a sample. There is faq.md beside ARCHIVE.md, and a file whose name contains spaces, Third Party Notices.md. A .gitmodules file is present too, so at least part of the tutorials material is pulled in as submodules rather than stored here.
None of that is described on the page, so a reader cloning the repository is discovering the layout by looking at it.
The audience is narrowed twice, and the last bullet stops mid word
Who this is for is answered in three lines. The difficulty is intermediate. The course assumes you are comfortable in the Unity Editor and can read and write C#. No robotics or ROS 2 experience is assumed, and the concepts are introduced as they come up.
That last reassurance sits next to the requirement for a ROS 2 virtual machine, which is a gap worth noticing: the course will not teach you ROS 2 and will not set it up, yet two of its five modules cannot be attempted without it.
The reading guide is the most considered paragraph on the page. Each module file puts concept blocks before each procedure, explaining what a thing is and how it works, and the stated reason is that when you deviate from the steps with a different robot, a different sensor or a different scene, you can still reason about what to do. The second bullet of that list, describing the numbered procedural steps, ends on the fragment Numbered procedural se.
The license field is unresolved while LICENSE.md is linked at the top
The page links a LICENSE.md file in its first line, next to the title, and the repository license metadata comes back as NOASSERTION, meaning no license could be determined. Those two facts do not agree, and which terms the file contains is not stated anywhere in the visible text, so it is not a call to make on the project's behalf.
It matters more than usual here, because the course tells you to copy its assets into a project of your own: a Panda URDF, a material fixer script, an AMR prefab and ROS 2 test files. Anyone reusing those files needs to know the terms first, and a linked file whose license the metadata cannot confirm is exactly the case to check.
For scale, the repository shows 2582 stars, 470 forks and 56 open issues, with no topics set. The open issue count is the number to watch on a repository whose content has been reorganised twice, from a tools hub to an archived set of packages to a course.
Editorial conclusion
Unity Robotics Hub is worth reading as a course rather than as a toolkit, and the two are no longer the same thing. The material assumes a Unity 6.3 project, a Simulation Pro install from the Package Manager, and for its last two modules a virtual machine running Ubuntu 26.04 with a specific ROS 2 distribution, which is a heavy floor for a five hour course and one that will age quickly. Before you plan around it, check whether Simulation Pro is actually available to you, since the page describes production support from Unity 6.3 with early access for industry developers and routes interest through a contact form. If your robot, sensors or scene differ from the ones described, the concept blocks are the part worth reading, since they exist precisely so the procedures can be adapted.
Frequently asked questions
What is the Unity Robotics Hub repository now?
It presents itself as a central repository for robotics simulation in Unity, and its current body is a written companion to a five module course about Simulation Pro, the package that adds robotics functionality directly to the Unity Editor.
What does Simulation Pro add to Unity?
Four capabilities: a URDF importer for drag and drop robot files, sensor simulation for Lidar, RGB-D and IMU, direct communication with ROS based hardware from Unity, and a headless Linux build target for parallel simulation across hardware stacks.
What are the modules in the Unity Robotics Hub course?
Five: introduction and the URDF importer, messages including a Dummy Connection and TF broadcasting, sensors covering camera, fisheye, stereo depth, time of flight, three LiDAR implementations and IMU, building a live simulation with an rclpy node navigating by LiDAR and odometry, and capturing images, point clouds and CSV logs.
What do I need to follow the Unity Robotics Hub modules?
Unity 6.3 or newer, Simulation Pro installed through the Package Manager, the Simulation Pro Basic and Prebuilt LiDAR Sensors samples, and course assets including the Panda URDF, a material fixer script, an AMR prefab and ROS 2 test files. Modules 4 and 5 additionally need Ubuntu 26.04 with ROS 2 Lyrical Luth on a virtual machine.
Does the Unity Robotics course teach ROS 2 setup?
No. The page states that setting up ROS 2 is out of scope, and points to the ROS 2 wiki for installation steps. The audience note says no robotics or ROS 2 experience is assumed.
Where is the older Unity Robotics content?
The page points at ARCHIVE.md for archived content on unsupported packages. The repository's newest release tag is v0.7.0 from 2022-02-03, while the last push is dated 2026-09-22.
Official sources
Add this badge to your README
If you maintain this project, the badge below links readers to this analysis and shows its maintenance status from the daily GitHub snapshot. Paste the markdown into your README; add ?metric=license or ?metric=stars to the image URL for a different field.
[](https://hysenlabs.com/projects/unity-technologies-unity-robotics-hub)Star history chart for your README
[](https://hysenlabs.com/projects/unity-technologies-unity-robotics-hub)Was this useful?