WebODM: decoupled from OpenDroneMap, AGPL licensed, four containers
User-friendly, commercial-grade software for processing aerial imagery. ✈️ Download it for free!
At a glance
- What is it?
- WebODM turns aerial imagery into georeferenced maps, point clouds, elevation models, textured 3D models and gaussian splats, and it now announces its decoupling from OpenDroneMap and uses its own processing engine. Its dependency file installs some packages from zip files attached to its own releases, its compose stack runs four services with hand-tuned out-of-memory priorities, and its manifest version, 3.3.2, matches the newest release.
- Who is it for?
- Use WebODM if you want the whole pipeline from drone images to point clouds or elevation models in a self-hosted stack you control, and if you are willing to run it as containers rather than a single binary. Check four things before you commit.
- Can I use it commercially?
- Yes, with strict conditions. AGPL-3.0 is a network copyleft licence: if people use a modified version over a network, for example as a hosted service, you must offer them its source code under the same licence.
- Is it still maintained?
- Yes. The repository received new commits within the last day.
- What is it written in?
- Mainly Python, according to GitHub's language statistics.
Answers come from the project's GitHub data, last synced on November 15, 2026, and from our analysis. They are not legal advice.
Star history
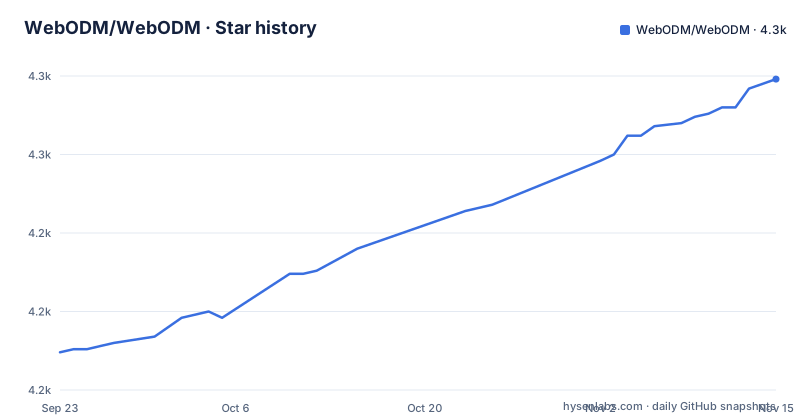
- WebODM/WebODM4,274 ★ · +87
| Repository | 2026-09-23 | 2026-11-15 |
|---|---|---|
| WebODM/WebODM | 4.2k | 4.3k |
87 Stars in the last 53 days, measured from the daily GitHub snapshot. Compare with other projects
Editorial analysis
The decoupling is the headline, and it changes the default engine
The first thing the readme announces is a separation.
WebODM has officially decoupled from OpenDroneMap, and there is a blog post behind that announcement.
Then the notes spell out what decoupling means in practice. WebODM is not affiliated with that project and is not a user interface to it. For processing, WebODM uses a different engine, and the readme is explicit that it is not the one that project's users would expect.
So two defaults changed at once. The project that WebODM grew out of is no longer its parent, and the software that does the photogrammetry is no longer the software that project's name implies.
That is why the engine list matters. The readme names three processing engines it supports: its own, plus two others, one of them a separate microservice project and one documented on a different site.
Anyone upgrading an existing installation should read that announcement before anything else, because an installation built around the previous engine is not the same product as the one described here.
A paid installer after April 2026 is a different product
One note in the readme is about money, and it is unusually direct.
Official, up-to-date WebODM installers are free to download, and the note adds that if you paid for an installer after April 2026, you bought different software.
That sentence is doing two jobs. It tells a prospective user that the official download is free, and it tells someone who already paid that their file is not this project.
The readme also links a guide on how to migrate from a purchased installer.
For anyone evaluating it now, the checks are simple and all of them are on the page: the licence is the GNU Affero General Public License version 3, the official installers are free, and there is a separate trademark policy file in the repository. The code is open; the name is not a grant.
The manifest is one patch ahead of the newest tag
The most recent release is 3.3.2, published on October 29, 2026, and the package manifest in the repository declares the same version, 3.3.2.
The test command in that manifest does something unusual: it runs a Python test through the project's management script before running the JavaScript test runner, and there is a second script that runs only the JavaScript half.
"scripts": {
    "test": "python manage.py test app.tests.test_generate_ui_mocks && jest",
    "qtest": "jest"
}
The first name runs both halves, the second runs only the fast half. That split is a small thing to know before you conclude that the tests did not run.
Some Python dependencies are zip files in this repository's own releases
The dependency file is a mix of ordinary package pins and direct downloads, and the downloads are the interesting part.
Several lines are URLs pointing at zip files or wheels attached to releases of this project itself.
https://github.com/WebODM/WebODM/releases/download/v3.1.1/celery-4.4.0-pytz.zipOne task queue, one raster tiling pair, and two builds of the geospatial raster library, each pinned to a release tag.
The geospatial entries carry environment markers, so the list branches by architecture and platform: one build for x86 Linux and macOS, a different archive for ARM Linux and macOS, a wheel for Windows, and a matching set of other Windows-only packages behind the same marker style.
That means an installation is not just a list of package names. It is a list of package names plus five binary artifacts that have to exist somewhere reachable, and for an air-gapped or mirrored deployment they have to be mirrored too.
The rest of the file is conventional and pins framework versions explicitly, which is why the list is worth reading end to end before you plan a build.
Four services, and memory priority is set deliberately
The default compose file defines four services, and its first comment sets expectations.
The comment says this configuration does not include a processing node, and that this makes for faster setup times.
So the stack you get by default is not the full product. It is the web interface, its database, its message broker and its worker, with the part that does the photogrammetry left out.
Each service has a memory priority adjustment, and the values are not decorative. The broker has a strongly negative value, the database a mildly negative one, the web application zero, and the worker a positive one. That ordering is a memory pressure strategy: under out-of-memory pressure the kernel reclaims from the worker first, and the broker survives longest, so a heavy job cannot take the queue down with it.
The two application services share an image and differ mainly in what they run. The web application starts cron, waits for the database and the broker, then starts the main script; the worker waits for the database, the broker and the web application on port 8000, then runs the worker script. Both mount the same media volume.
Twenty compose files, four wait-for scripts, and a committed .env
The repository root is mostly configuration, and the count is the story.
There are thirteen compose files, and their names describe the variations: development, build, IPv6, SSL with a managed certificate and SSL configured by hand, one per worker resource profile, one for settings, one for the engine that runs as a microservice, one for a GPU variant, and one that adds a volume.
Beside them sit two shell scripts whose only job is to wait: wait-for-postgres.sh for the database and wait-for-it.sh for another service on a port. The compose entrypoints call them in sequence before starting anything, because a container that depends on a database is not the same as a container that waits for one to answer.
Two other entries are worth noting. There is a settings file and a local environment file in the root, which means the environment a developer edits is in version control rather than ignored.
And the tooling around it is conventional: a dependency update configuration for the Python side, a babel configuration, a webpack configuration, a jest configuration, a Python management script at the root, a localisation directory with its own configuration file, and a document listing the locales the project ships.
The image adds a Python repository and a Node repository by hand
The container build is a multi-stage image on a single distribution release, and two of its early steps reach outside that distribution.
ARG NODE_MAJOR=20
ARG PYTHON_VERSION=3.9
ARG RELEASE_CODENAME=jammy
Python 3.9 is not the default on that image, so the build adds a third-party repository for extra Python versions, imports its signing key into the trusted key directory, and writes a source line for it. Node 20 is installed the same way, with its own repository and key.
That is a normal pattern and it is also a supply chain decision baked into an image definition: two external repositories are trusted at build time for the interpreter and the build tooling.
The rest of the stage installs the native build dependencies the geospatial stack needs, including a compiler, CMake and a point cloud library, then pip installs from the dependency file described earlier.
One comment in the file is worth reading if you build outside Docker. The multi-line run form used throughout requires Docker's shell wrapper, and it does not work with Podman unless you build in Docker compatibility mode.
Editorial conclusion
Use WebODM if you want the whole pipeline from drone images to point clouds or elevation models in a self-hosted stack you control, and if you are willing to run it as containers rather than a single binary. Check four things before you commit. It is no longer affiliated with OpenDroneMap and it processes with its own engine, so anything you knew about that project's defaults may not apply. The free installer is still the official one, and a paid installer sold after April 2026 is a different product. The Python dependency list pins several packages to zip files attached to this repository's own releases, so an air-gapped build needs those assets mirrored. And the compose stack assumes four services plus optional processing nodes, with memory priorities tuned so the broker survives first, which is the shape to design your hardware around rather than a single container.
Frequently asked questions
Is WebODM free?
The official installers are free, and the code is licensed under the GNU Affero General Public License version 3. The readme also warns that if you paid for an installer after April 2026 you bought different software, and it has a separate trademark policy.
What can WebODM do?
It processes drone and other aerial imagery and produces georeferenced maps, point clouds, elevation models, textured three dimensional models and gaussian splats. It supports multiple processing engines.
Is WebODM still related to OpenDroneMap?
No. The readme announces that WebODM has officially decoupled from it, states that WebODM is not affiliated with it and is not a user interface to it, and says processing uses its own engine rather than the one that project provides.
Which processing engines does WebODM support?
Three, named in the readme: its own engine, a separate microservice project for the photogrammetry step, and a third engine documented on a different site. The default compose file deliberately omits the processing node for faster setup.
What does the default WebODM compose file start?
Four services: the database, a Redis broker, the web application and a worker. The web application and the worker share an image, and the worker is given a higher out-of-memory priority value than everything else so that a heavy job is reclaimed before the queue.
Why does WebODM install some Python packages from URLs?
Several lines in its dependency file point at zip files and wheels attached to releases of WebODM itself, for the task queue and for two builds of the geospatial raster library, with platform markers selecting different builds per architecture and operating system.
Official sources
Add this badge to your README
If you maintain this project, the badge below links readers to this analysis and shows its maintenance status from the daily GitHub snapshot. Paste the markdown into your README; add ?metric=license or ?metric=stars to the image URL for a different field.
[](https://hysenlabs.com/projects/webodm-webodm)Star history chart for your README
[](https://hysenlabs.com/projects/webodm-webodm)Was this useful?