VESC firmware's board list is a glob of header filenames, and the GPL text is not in the repository
The VESC motor control firmware
At a glance
- What is it?
- C firmware for a brushless motor controller, built with a hand-rolled make system and an in-tree RTOS frozen at a 2018 release, with a vendored Lisp interpreter and a vendored debug probe. The repository contains no licence file and no releases, its release tags are created by hand, the build instructions clone over plain HTTP, and the readme names an output directory the makefile does not use.
- Who is it for?
- This firmware is the right starting point if you are building a VESC-compatible controller and want the field-oriented control code rather than writing it, because the whole tree is present, the board variants are all buildable from one checkout, and the recovery path when a board is bricked is documented rather than guessed at. Three things to know.
- Can I use it commercially?
- Not without permission. GitHub finds no licence file in the repository, and without a licence all rights are reserved by default: you may read the code but not reuse it. Check the README, or ask the authors, before using it.
- Is it still maintained?
- Yes. The repository last received commits 6 days ago.
- What is it written in?
- Mainly C, according to GitHub's language statistics.
Answers come from the project's GitHub data, last synced on November 15, 2026, and from our analysis. They are not legal advice.
Star history
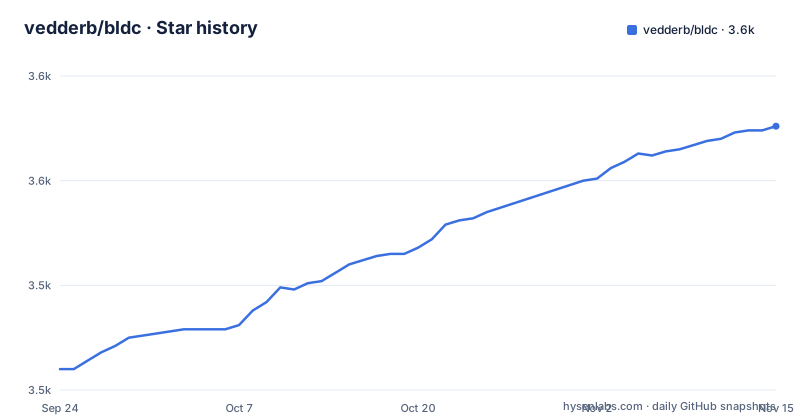
- vedderb/bldc3,576 ★ · +116
| Repository | 2026-09-24 | 2026-11-15 |
|---|---|---|
| vedderb/bldc | 3.5k | 3.6k |
116 Stars in the last 52 days, measured from the daily GitHub snapshot. Compare with other projects
Editorial analysis
The supported board list is a glob over header filenames
The readme answers the question of which boards are supported with two words: all of them. Then it tells you to find out by typing the make command with no target, and shows a snippet of the resulting help text listing a few board names. The makefile explains how that list is produced, and the mechanism is the interesting part. A recursive wildcard function walks a directory, collects the header files, throws out a shared core header, then strips the directory prefix and the file prefix and the extension to get a name, and sorts the result. There is no manifest of boards anywhere. The set of supported hardware is the set of filenames in one directory, which means adding a board is adding a file and a board cannot be listed unless someone has already written its header. It is elegant, and it also means a typo in a filename becomes a build target nobody documented. The help output itself is the only listing that exists:
[Firmware]
     fw   - Build firmware for default target
                            supported boards are: 100_250 100_250_no_limits 100_500...
The GPL text is not in the repository
The readme states that the software is released under version 3 of the GNU General Public License, and there is a badge linking to the licence page. The licence field on the repository comes through as unrecognised rather than as a value. And there is no licence file in the tree: no licence file and no copying file at the root, only the readme's sentence. For a project distributed as source on a code hosting site, that is the one file every downstream packager and every compliance check looks for first, and its absence means a packager has nothing to ship as the licence text and a distributor has to take the readme's sentence on trust. It is the kind of gap that survives for years precisely because it is nobody's urgent problem.
An RTOS from 2018 and a Lisp interpreter are both vendored in-tree
The repository contains three substantial third-party components as directories rather than as dependencies: an operating system kernel directory named for the kernel and for a specific version of it, a directory for a bytecode-pinned CAN protocol stack, and a directory for an embedded Lisp implementation. Vendoring a kernel at a named old version is the load-bearing choice here, because a motor controller needs a real-time kernel and the version it is pinned to predates most current firmware. The Lisp interpreter is the one that surprises people: the controller runs scripts, which is what makes the firmware configurable and extensible in a way a pure C firmware is not, and it is also a large piece of third-party code inside the licence boundary of this repository. A debug probe implementation is vendored too, for debugging over USB.
The build overrides environment variables on purpose
The makefile contains a macro whose entire job is to strip variables out of the build environment, and it announces each one it removes with a note. Two variables are on the list, both named as things that can influence the compiler in unexpected and undesirable ways, and the macro both overrides and unexports them so they cannot reach the compiler at all. This is unusual and sensible: build reproducibility on embedded toolchains usually fails because somebody's shell has a variable set that the cross-compiler wrapper interprets. The other half of the build system is a directory of included make fragments, split by operating system family and by tool, with paths derived from the makefile's own location so the build works from any working directory.
The readme's output directory does not match the makefile
The build instructions are four steps: check out the default branch, install the ARM SDK with a make target, run make with your board name, and run make again with the board name to build. The output is described as landing in a directory under the repository whose name is plural, followed by the board name and a binary file with the same name. The makefile declares a build directory variable with the singular form. One of those two is stale, and a newcomer who builds and then looks in the directory the documentation named will conclude the build failed. The documentation also tells you to pick the target name by running make first, which is the mechanism from the previous section rather than a documented list, so the one place the answer is supposed to be is a directory whose name is wrong.
Nix builds every board and cannot flash
There is a second build path through a Nix flake, with a lock file and a directory of packages in the tree. It is two commands: enable flakes and build one attribute from the repository root. The flake builds the general purpose firmware package, and the documentation is explicit about two consequences. All boards are built by default rather than one selected target, which is the right default for a reproducible artifact and a slow one. And the flash helpers, the make targets that program a board over a debug probe, are not supported through this path at all, so the Nix build produces binaries you then flash by hand or through the desktop tool. The packaged output is a directory containing the firmware and a Qt resource file.
Releases are tags typed by hand, which is why there are no releases
The repository has published no releases, and the readme has a section explaining why in the most literal way possible: every firmware release has a tag, and here is the two-line command sequence for creating one, which tags a named commit with an annotated message whose text the author types and then pushes the tags. So the version history is two git commands run manually, the message format is a convention rather than a field, and nothing validates that the tag matches the firmware metadata inside the build. There is a changelog file in the tree and a script whose name suggests it packages the firmware, so the artefacts exist; what does not exist is any automation connecting them. A distributor pinning a firmware version has a tag to pin and nothing else to verify it against.
Setup fetches a udev rule from a personal domain over plain HTTP
Two details in the setup are worth pausing on. The clone instructions in both the Unix and the Windows sections use a plain HTTP address for the repository rather than HTTPS, which is the kind of thing that gets copied into scripts for years. And the optional step that lets a programmer work without root privileges fetches a udev rules file from a personal domain over that same plain HTTP and moves it into a system rules directory as root, then asks the system to reload the rules. The step is genuinely useful, since running the programmer as root on a machine you share is worse than a udev rule. The Windows instructions have the opposite kind of honesty, telling you not to run the shell as administrator because doing so will break the build.
Editorial conclusion
This firmware is the right starting point if you are building a VESC-compatible controller and want the field-oriented control code rather than writing it, because the whole tree is present, the board variants are all buildable from one checkout, and the recovery path when a board is bricked is documented rather than guessed at. Three things to know. There is no licence file in the repository at all, only a statement in the readme and a badge, which for a GPL project is a gap you should raise with the maintainer before redistributing anything derived from it. The build sanitises environment variables that can change compiler behaviour, so an unusual shell setup will produce a different result than you expect. And the readme's own build path clones over plain HTTP and installs a udev rule fetched from a personal domain into a system directory, which is fine for a one-off at a workbench and not something to paste into a build script.
Frequently asked questions
What is the purpose of a BLDC motor controller?
It drives a brushless motor by switching its phases in the right sequence and timing, and this repository is the firmware for one such controller. It supports direct current, brushless and field-oriented control on the same hardware.
How do I find out which boards the VESC firmware supports?
Run make with no target and read the firmware help it prints. The list is generated by globbing the header files in the hardware configuration directory and stripping their prefixes, so there is no manifest to read.
What licence is the VESC firmware under?
The GNU General Public License version 3.0, stated in the readme and in a badge. There is no licence file in the repository, and the repository's licence field does not carry a value.
How do I flash firmware to a VESC?
Two documented routes. One programs the board over a debug probe using a flash make target, after building a separate bootloader. The other builds the firmware as a binary and uploads it through the desktop tool over USB, with explicit warnings not to disconnect power during the upload and to wait ten seconds after the progress bar completes.
Can I recover a VESC that will not boot?
Uploading firmware to a board that no longer runs requires a debug probe, so recovery depends on hardware rather than on the USB upload path. The readme states this directly in its own section on bricked boards.
Official sources
Add this badge to your README
If you maintain this project, the badge below links readers to this analysis and shows its maintenance status from the daily GitHub snapshot. Paste the markdown into your README; add ?metric=license or ?metric=stars to the image URL for a different field.
[](https://hysenlabs.com/projects/vedderb-bldc)Star history chart for your README
[](https://hysenlabs.com/projects/vedderb-bldc)Was this useful?