PythonRobotics: a teaching codebase for robotics algorithms, not a runtime library
Python sample codes and textbook for robotics algorithms.
At a glance
- What is it?
- PythonRobotics is a collection of standalone Python sample scripts plus a companion online textbook, covering localization, mapping, SLAM, path planning, path tracking, arm, aerial and bipedal examples. Its value is pedagogical clarity under minimal dependencies; it is not packaged as an installable library with a stable API.
- Who is it for?
- Adopt PythonRobotics if you are learning a specific algorithm and want to read its implementation next to a textbook chapter, or if you need a reference implementation to port into your own stack. Do not adopt it if you need an installable package with a versioned API, since the README describes cloning the repository and running scripts inside each directory, and the repository lists no releases.
- Can I use it commercially?
- Check first. The repository uses a licence we do not classify automatically, so read its LICENSE file before any commercial use.
- Is it still maintained?
- Yes. The repository last received commits 4 days ago.
- What is it written in?
- Mainly Python, according to GitHub's language statistics.
Answers come from the project's GitHub data, last synced on November 13, 2026, and from our analysis. They are not legal advice.
Star history
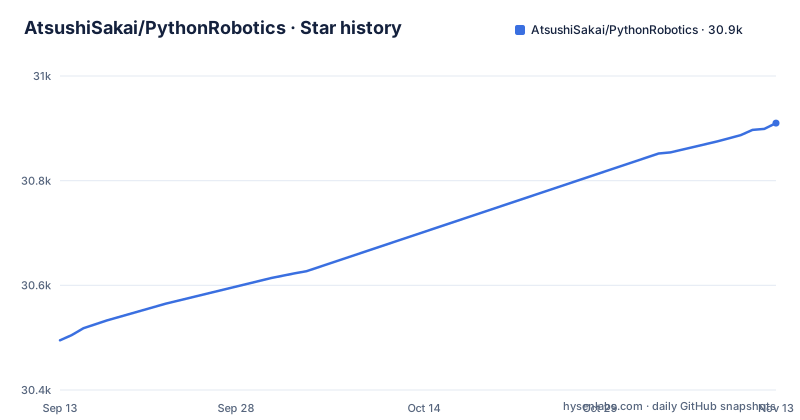
- AtsushiSakai/PythonRobotics30,910 ★ · +415
| Repository | 2026-09-13 | 2026-11-13 |
|---|---|---|
| AtsushiSakai/PythonRobotics | 30.5k | 30.9k |
415 Stars in the last 61 days, measured from the daily GitHub snapshot. Compare with other projects
Editorial analysis
The gap PythonRobotics fills is comprehension, not deployment
Most robotics algorithm descriptions live in papers, and most production implementations live inside large frameworks where the algorithm is entangled with message passing, threading and hardware drivers. PythonRobotics takes the opposite position. The README states three features: the code is meant to be easy to read for understanding each algorithm's basic idea, widely used and practical algorithms are selected, and dependencies are kept to a minimum. The repository backs that claim in a narrow sense. Each algorithm is a script under its own directory, and the README says to execute the Python script in each directory rather than import a package. The audience is therefore a student, a researcher, or an engineer who wants to see how an extended Kalman filter, an RRT variant or a Stanley controller is actually written in a few hundred lines of NumPy. It is a textbook with runnable figures, not a component you drop into a robot.
What the table of contents actually covers
The README's table of contents is the most useful specification of scope. Localization includes extended Kalman filter, particle filter and histogram filter localization. Mapping includes Gaussian grid map, ray casting grid map, lidar to grid map, k-means object clustering and rectangle fitting. SLAM includes iterative closest point matching and FastSLAM 1.0. Path planning is the largest group: dynamic window approach, Dijkstra, A*, D*, D* Lite, potential field, grid based coverage planning, particle swarm optimization, state lattice planning with biased polar and lane sampling, probabilistic road maps, RRT with RRT*, RRT* with reeds-shepp path and LQR-RRT*, quintic polynomials, reeds shepp planning, LQR based path planning, and optimal trajectory in a Frenet frame. Path tracking covers move to a pose, Stanley, rear wheel feedback, LQR and model predictive speed and steering control, plus nonlinear model predictive control with C-GMRES. Arm navigation, aerial navigation with drone 3D trajectory following and rocket powered landing, and a bipedal planner with inverted pendulum round out the list. Breadth is real, but depth per algorithm is deliberately limited to what fits a readable script.
How the code is organised and how data moves through a sample
The repository is organised by topic, with top-level directories such as Localization, Mapping, SLAM, PathPlanning, PathTracking, ArmNavigation, AerialNavigation and Bipedal, alongside utils/ and tests/. Animation GIFs are not stored in this repository; the README points to a separate repository, AtsushiSakai/PythonRoboticsGifs, for all animation GIFs. That separation matters if you are browsing: the images embedded in the README are loaded from that second repository.
Getting a sample running, and the dependency set it pulls in
The README's How to use section lists clone, install and run steps (its fourth step is a request to star the repo). Clone the repository with git clone https://github.com/AtsushiSakai/PythonRobotics.git. Install the required libraries either with conda env create -f requirements/environment.yml or with pip install -r requirements/requirements.txt. Then execute the Python script in each directory. The runtime requirements listed are Python 3.13.x, NumPy, SciPy, Matplotlib and cvxpy. Development requirements are pytest, pytest-xdist for parallel unit tests, mypy for type checking, sphinx for document generation, and pycodestyle for code style checks. The repository carries CI configuration (.circleci/ and appveyor.yml), and the README shows an AppVeyor build badge. Note that cvxpy is a convex optimisation modelling layer, so it is only relevant to the samples that formulate optimisation problems; installing the full requirements file brings it in regardless of which script you intend to read.
The limitation: scripts, not a library, and no releases
The single most important constraint is that PythonRobotics is not distributed as an importable package. The README instructs you to clone the repository and run scripts in place. The README gives no pip install command for the project itself, and the repository publishes no releases, so there is no version number to pin against. That has two consequences. First, if you copy an algorithm into your own codebase, you own it from that moment; upstream changes will not reach you and there is no deprecation path to warn you. Second, the scripts are written for demonstration, not for real time control loops. The README's own framing supports this reading: it describes the repository as Python codes and a textbook for robotics algorithm, and the documentation as the place to look for mathematical backgrounds.
Where a packaged alternative wins instead
If you need a maintained, installable implementation with a versioned API, the appropriate comparison is a robotics framework with released packages, such as ROS 2 navigation components or a dedicated planning library, rather than another teaching repository. The difference in approach is structural. PythonRobotics gives you one file per algorithm with simulated inputs and Matplotlib output, which is ideal for reading the mathematics in code. A framework gives you an algorithm behind an interface, with message types, parameters loaded from configuration, lifecycle management and tested integration with sensors, at the cost of the algorithm being harder to see. Neither substitutes for the other. A reasonable pattern is to read the PythonRobotics script to understand the method, then implement or configure the method inside the framework you actually deploy, using the script as a specification of the update equations rather than as code to ship.
Maintenance, licence and upgrade posture
The repository is not archived and the last push recorded in the metadata is 2026-10-04, so it is active. The primary language is Python, and the README lists Python 3.13.x as the runtime, which means following the project requires keeping pace with Python releases and with NumPy, SciPy, Matplotlib and cvxpy. Because the repository publishes no releases, upgrading means pulling the master branch and re-reading the scripts you depend on; there is no semantic versioning signal to tell you whether a change is breaking. The licence field reports NOASSERTION, which in practice means the automated classifier could not map the repository's licence file to a known identifier. That is not the same as having no licence, and it is not the same as a permissive licence. If you intend to copy code, read the LICENSE file at the repository root yourself and confirm the terms before you rely on them. This is a description of what the metadata says, not legal advice.
Who this is for, and the first thing to check
Use PythonRobotics when the goal is understanding. A course, a paper reproduction, a design review where you need to argue about how D* Lite backs up costs, or an interview preparation session on model predictive speed and steering control all fit. The companion textbook at atsushisakai.github.io/PythonRobotics is the intended entry point for the mathematics, and the paper at arXiv 1808.10703 is cited in the README for more detail. The first thing to verify before you commit to it is the licence file, because the metadata will not answer that question for you, and the second is whether the specific algorithm you need is in the table of contents at all, since the selection is described as widely used and practical rather than exhaustive.
Editorial conclusion
Adopt PythonRobotics if you are learning a specific algorithm and want to read its implementation next to a textbook chapter, or if you need a reference implementation to port into your own stack. Do not adopt it if you need an installable package with a versioned API, since the README describes cloning the repository and running scripts inside each directory, and the repository lists no releases. Before depending on any file, check the licence situation: the repository metadata reports NOASSERTION, so read the LICENSE file at the repository root yourself and confirm the terms with whoever owns the code you are copying.
Frequently asked questions
What is Python robotics?
PythonRobotics is a Python code collection and a free online textbook of robotics algorithms, covering localization, mapping, SLAM, path planning, path tracking, arm navigation, aerial navigation, and bipedal motion.
Is there a Python toolbox for robotics?
PythonRobotics is a code collection rather than an importable library. You clone the repository, install the requirements, and execute the Python script inside the directory of the algorithm you want to run.
what is python robotics
It is a set of Python sample codes paired with a textbook, whose stated features are readability of each algorithm's basic idea, selection of widely used practical algorithms, and minimum dependency. It requires Python 3.13.x, with NumPy, SciPy, Matplotlib, and cvxpy.
Official sources
Add this badge to your README
If you maintain this project, the badge below links readers to this analysis and shows its maintenance status from the daily GitHub snapshot. Paste the markdown into your README; add ?metric=license or ?metric=stars to the image URL for a different field.
[](https://hysenlabs.com/projects/atsushisakai-pythonrobotics)Star history chart for your README
[](https://hysenlabs.com/projects/atsushisakai-pythonrobotics)Was this useful?