sjtuyinjie/SJTU_GVI: five car sequences for GNSS-visual-inertial SLAM
A GNSS-Visual-IMU Dataset for SLAM
At a glance
- What is it?
- A small benchmark dataset rather than a system: five rosbag sequences recorded on a real car in a single session, with raw GNSS from a Ublox ZED-F9P receiver, camera intrinsics and camera-to-IMU extrinsics in the repository, and ground truth alongside. It exists as the test data for an M2C-GVIO paper and is deliberately lighter than the M2DGR dataset it is compared against.
- Who is it for?
- Use this dataset if you are working on GNSS-aided visual-inertial odometry for ground vehicles and want a dataset small enough to download in an afternoon, with the receiver's raw measurements rather than a fused solution. Two things to plan for.
- Can I use it commercially?
- Not without permission. GitHub finds no licence file in the repository, and without a licence all rights are reserved by default: you may read the code but not reuse it. Check the README, or ask the authors, before using it.
- Is it still maintained?
- Probably not. The repository last received commits 24 months ago, on November 22, 2024.
- What is it written in?
- GitHub does not report a main language for this repository.
Answers come from the project's GitHub data, last synced on November 15, 2026, and from our analysis. They are not legal advice.
Star history
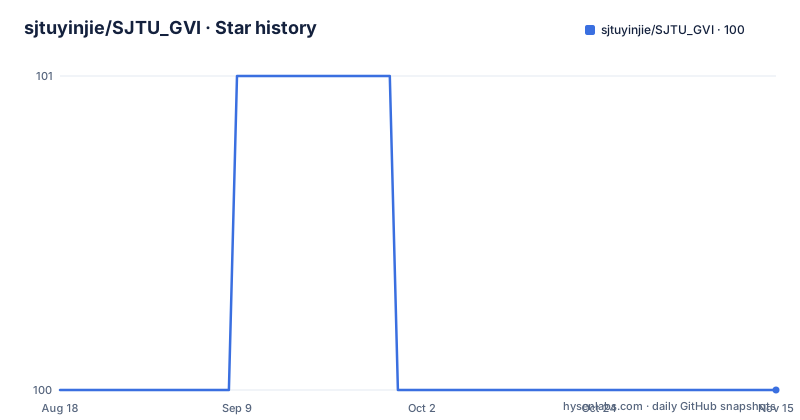
- sjtuyinjie/SJTU_GVI100 ★ · +0
| Repository | 2026-08-18 | 2026-11-15 |
|---|---|---|
| sjtuyinjie/SJTU_GVI | 100 | 100 |
0 Stars in the last 89 days, measured from the daily GitHub snapshot. Compare with other projects
Editorial analysis
The repository holds three things and no code
This is a data repository, and the file tree says so directly. The top level contains a README, a directory named `calibrations` and a directory named `data`, and nothing else: no source directory, no build file, no licence file, and no recorded programming language. Everything a user needs therefore arrives through the README, through two links into those directories, or through the download links it points at. That has a practical consequence for anyone evaluating it. You cannot run anything here, there is no script to regenerate the sequences or check them, and the absence of a licence file means the terms for redistributing or publishing derived work are not stated anywhere in the repository.
The citation request points at the other dataset
The attribution section is the one place where the README is genuinely confusing, and it is worth reading twice. After asking for a star if the project helped your research, it tells you that if you use M2DGR in academic work you should cite a given reference, and the two entries it prints are for M2DGR and for M2C-GVIO. The M2DGR entry names five authors, appears in IEEE Robotics and Automation Letters from 2021, and carries a digital object identifier. The M2C-GVIO entry names six authors and appears in Satellite Navigation, volume 4, number 1, pages 1 to 15, published by SpringerOpen in 2023. So the repository asks you to cite the parent dataset while hosting the sequences, and the two entries are formatted with different fence styles in the same file, one using three tildes and the other two.
Three differences from M2DGR are the pitch
The comparison against the larger dataset is stated as a short list, and it is the only argument the README makes for using this one. First, it is more lightweight and easier to download. Second, it was recorded on a real car with high speed, which the README presents as a contrast rather than a detail. Third, the GNSS raw measurements are captured by a Ublox ZED-F9P receiver, which the README says facilitates GNSS-SLAM research. That third point is the substantive one, because a raw receiver output gives you more than a corrected position estimate, and it is the reason the dataset exists separately from the sensor fusion it was used to evaluate. The paper this data supports is M2C-GVIO, on motion manifold constraint aided GNSS-visual-inertial odometry for ground vehicles.
Five sequences from one collection day
The sequence table is the core of the dataset, and it is small enough to read in full. All five were collected on the same date, 2021-12-23, which means they are five drives rather than a campaign spread over time.
| Sequence | Collection Date | Total Size | Duration | |---|---|---|---| | Seq1 | 2021-12-23 | 2.37G | 349s | | Seq2 | 2021-12-23 | 921M | 109s | | Seq3 | 2021-12-23 | 1.19G | 146s | | Seq4 | 2021-12-23 | 850M | 112s | | Seq5 | 2021-12-23 | 1.26G | 159s |
Together that is roughly six and a half gigabytes and about fifteen minutes of data in total, with the longest single run just under six minutes. The size range reflects the light-weight framing: no single sequence is more than a couple of gigabytes, which is what makes downloading all five a reasonable proposition rather than a negotiation.
Every rosbag comes from a Baidu Pan share
The download column is the one practical constraint in the table. Each of the five sequences links to a share on Baidu's network storage rather than to a direct file URL, a university mirror or an archive with a checksum. The README publishes no file sizes beyond the rounded figures in the table, no hashes, and no notes about what each bag contains. That combination means a researcher cannot verify an integrity check on what they download, and cannot be sure a link is still live until they try it. If you are reproducing a published result with this data, copy the bags to storage you control as soon as they arrive, since the durability of a shared link is not something the repository can promise.
Calibration and ground truth are in the repository
Two directories do the work that the README delegates. The calibration section points at a directory in the repository for the camera intrinsic calibration and the camera-to-IMU extrinsic calibration results, and a figure caption in the README shows them calibrating the extrinsics during the session. The ground truth section points at a second directory. So the parts you cannot derive from the raw bags yourself are committed to the repository rather than hosted elsewhere, which is the main reason this is a repository at all rather than a download page. Two figure captions give the only description of the hardware: one shows the acquisition platform, and the other shows the extrinsic calibration.
The extraction code is named and not explained
The sequence section opens with a single sentence that has no elaboration anywhere else in the file: the extraction code is given as a string of five characters. Whether that is an identifier for the authors' internal extraction tooling, a naming convention for the sequences, or something else is not stated, and no code implementing it is present in the repository. The same economy applies to the acknowledgement section, which thanks one company by its full registered name for support. Taken together with the three-item top level, the picture is of a dataset published to make a paper's experiments reproducible: the sequences, the calibration, the ground truth and the citation instructions, and little else. The last push to main is dated 2024-11-22 and no releases are published.
Editorial conclusion
Use this dataset if you are working on GNSS-aided visual-inertial odometry for ground vehicles and want a dataset small enough to download in an afternoon, with the receiver's raw measurements rather than a fused solution. Two things to plan for. Every rosbag is behind a Baidu Pan share link, so availability outside that service is not something the repository controls, and the README publishes no checksums to verify a download against. And read the citation section carefully, because the request there is to cite the M2DGR dataset rather than this one. The last push to main is dated 2024-11-22 and the repository publishes no releases.
Frequently asked questions
What is the SJTU_GVI dataset?
A GNSS, visual and IMU benchmark dataset for SLAM, and part of the test data for the M2C-GVIO paper on motion manifold constraint aided GNSS-visual-inertial odometry for ground vehicles. It contains five sequences recorded on 2021-12-23.
How is SJTU_GVI different from M2DGR?
Three differences are given: it is more lightweight and easier to download, it was recorded on a real car at high speed, and the GNSS raw measurements come from a Ublox ZED-F9P receiver, which the README says facilitates GNSS-SLAM research.
How do I download the SJTU_GVI sequences?
Each of the five sequences has a rosbag link in the sequence table, and all of them point to share links on Baidu Pan. The README publishes no direct file URLs and no checksums, so a download cannot be verified against a hash.
Where are the calibration and ground truth files for SJTU_GVI?
In the repository itself. The camera intrinsic and camera-to-IMU extrinsic calibration results are in a calibrations directory, and the ground truth is in a data directory, each linked from its own section of the README.
What should I cite if I use SJTU_GVI?
The README asks you to cite M2DGR if you use it in academic work, and prints two reference entries, one for M2DGR in IEEE Robotics and Automation Letters from 2021 and one for M2C-GVIO in Satellite Navigation in 2023.
Official sources
Add this badge to your README
If you maintain this project, the badge below links readers to this analysis and shows its maintenance status from the daily GitHub snapshot. Paste the markdown into your README; add ?metric=license or ?metric=stars to the image URL for a different field.
[](https://hysenlabs.com/projects/sjtuyinjie-sjtu-gvi)Star history chart for your README
[](https://hysenlabs.com/projects/sjtuyinjie-sjtu-gvi)Was this useful?