VolAnti: acoustic drone detection for the aircraft that never transmits
Open-source acoustic drone detection. It hears the propellers, not the radio, so it works against fibre-optic FPV aircraft that emit no signal at all.
At a glance
- What is it?
- VolAnti is an open-hardware acoustic detector built around four MEMS microphones, an ESP32-S3 and a LoRa radio. It listens for the harmonic comb of a propeller instead of a control link, which is the only signal a fibre-optic FPV drone cannot suppress.
- Who is it for?
- Adopt VolAnti if you need a cheap local tripwire for the last few hundred metres and you are willing to build and repair the hardware yourself; the repository ships firmware, PCB, BOM and a printable enclosure, and the README puts a full unit at £50 to £80 in parts.
- Can I use it commercially?
- Check first. The repository uses a licence we do not classify automatically, so read its LICENSE file before any commercial use.
- Is it still maintained?
- Yes. The repository last received commits 19 days ago.
- What is it written in?
- Mainly C, according to GitHub's language statistics.
Answers come from the project's GitHub data, last synced on November 15, 2026, and from our analysis. They are not legal advice.
Star history
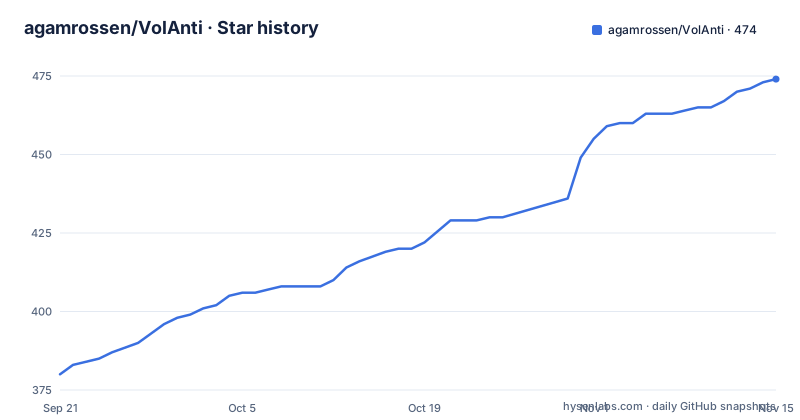
- agamrossen/VolAnti474 ★ · +94
| Repository | 2026-09-21 | 2026-11-15 |
|---|---|---|
| agamrossen/VolAnti | 380 | 474 |
94 Stars in the last 55 days, measured from the daily GitHub snapshot. Compare with other projects
Editorial analysis
The gap VolAnti targets: drones that carry no radio at all
Most drone detection starts with the control link. The README describes that approach plainly: find the radio between pilot and aircraft, decode it, and report both positions. It works, and it has one hard failure, because the drone has to transmit. A fibre-optic FPV aircraft trails a thread of glass back to its operator, sends video down the fibre and control up it, and leaves the radio spectrum silent. There is nothing to find and nothing to decode.
The airframe cannot hide the motors. A 7 in three-blade propeller on a 2807-class motor puts a structured comb of harmonics into the air, spaced by the blade-passage rate. VolAnti listens for that structure. The project is explicit that it is not radar and not a replacement for one; it positions itself as a cheap local tripwire for the last few hundred metres, something a school or a farm can build and repair themselves. That framing matters when you decide whether it fits. If your threat model is a radio-controlled quadcopter at 2 km, radio detection is the better tool. If your concern is an aircraft that emits nothing at all, acoustics is one of the few passive options left.
How the comb score and the adaptive floor work together
The mechanism is a spectrum pipeline, not a neural network. A propeller with B blades turning at R revolutions per second chops the air B times R times a second. That is the fundamental, and because the chopping is not a smooth sine, energy also lands at multiples of it, producing peaks at even spacing with quiet gaps between. Wind, traffic and rain smear across the whole spectrum; evenly spaced teeth do not, and their spacing is the rotor speed.
The signal chain, as the README lays it out: four ICS-43434 MEMS microphones in a plus, 79 mm corner to corner, clocked from one source, with their four streams added. At these frequencies 79 mm is a tenth of a wavelength, so sound from any direction adds in phase while each capsule's own noise does not. The README credits that with about 6 dB of signal to noise and near-omnidirectional behaviour, and notes that beamforming was tried at this size and buys nothing. Then a 2048 point FFT every 512 samples at 16 kHz, one frame every 32 ms. An adaptive floor keeps a running picture of the site's normal sound at every frequency and subtracts it; quiet things are learned in about 6 s, loud broadband bursts in under a second, which is what stops a passing lorry parking itself in the noise model. For every candidate rate from 70 to 2000 Hz the detector adds the energy on that comb's teeth, subtracts the energy in its gaps, normalises and keeps the best. One high scoring frame means nothing: the same rate has to win six frames in a row within 2 %. Noise does not do that. A rotor does.
The design choice worth noticing is that there are four detectors on one spectrum rather than one tuned detector, because a single threshold would have to favour either an aircraft that arrives or one that hovers. The alert is whichever is sure first. The fast comb tier scores against the fast floor and is listed at 0.23 s latency.
Installing VolAnti: breadboard first, then the full unit
The repository gives two build paths. The README links a breadboard guide at docs/breadboard-build.md and a full unit guide at docs/pcb-build.md, with flashing instructions in docs/flashing.md. The breadboard route is the one to take before ordering a PCB, because it lets you confirm the microphones and the firmware on a bench before you commit to the enclosure.
Everything needed to build one is in the repository, which the README states directly. The hardware directory holds the PCB, BOM and placement files under hardware/pcb/ and the printable enclosure under hardware/enclosure/, the firmware lives in firmware/, the reference detector is in src/, and test audio is in test/. The top-level environment.yml is the entry point for the host-side tooling used with that reference detector, and it is described in the repository layout rather than in the README body.
If you only want to see the detector behave before buying any parts, the README points to a live simulator on the project website where you can watch it work on a sound field you control. That is the cheapest first step and it needs no hardware at all. The README also links a gallery of photos and videos, which is the quickest way to see what a finished unit looks like before you start printing and soldering.
What VolAnti cannot do, and where it is the wrong tool
The honest limitation is stated by the project itself: the array is a sensitivity device, not a direction finder. Four capsules added together give you a detection and a rough sense of the site, not a bearing. If your requirement is to know which direction the aircraft came from, or to hand a track to something else, this design does not produce that number, and beamforming at 79 mm was tried and rejected.
The range figure deserves the same care. The README reports 104 m measured detection against a hovering airframe in light wind. That is a specific test condition, not a general specification. Acoustic propagation is sensitive to wind, to background noise and to the airframe itself; the documentation does not claim the number holds for a moving aircraft, a different propeller or a noisier site. Treat 104 m as the best case the project measured, and read docs/test-results.md and docs/deploying.md before you plan coverage around it.
There is also a scope boundary that is not a limitation but a deliberate refusal. The README states detection and alert only, with no jamming, no interception and no countermeasures, ever. If your requirement includes any form of response beyond alerting, this project is not the one to evaluate. And it is not radar: it will not see a glider, a balloon or anything without a spinning propeller, and it cannot replace a wide-area radio or radar picture. It is a tripwire for the last few hundred metres, and it should be judged as one.
VolAnti against radio-frequency drone detection
The real alternative is RF detection, the approach the README describes first: listen for the control link, decode it, and report where the pilot and the aircraft are. The difference in approach is fundamental, not a matter of tuning. RF detection depends on the aircraft transmitting, and it can often give you a bearing and a pilot location because the link is structured and bidirectional. VolAnti depends on the aircraft making noise, and it gives you a detection with no bearing, but it keeps working when the spectrum is empty.
That makes the two complementary rather than competing. A site that already runs RF detection gains a second, independent channel that does not share the fibre-optic blind spot. A site with no detection at all gets a passive tripwire that costs £50 to £80 in parts and can be repaired by whoever built it. The trade is coverage and precision for independence from the radio spectrum and for a bill of materials a school can afford.
One more difference is worth naming. RF detection is a software problem on commodity hardware; VolAnti is a hardware project with a PCB, a BOM, an enclosure and a firmware image, and the README treats building it as part of the point. If you want to buy a box and plug it in, this is the wrong shape of project. If you want something you can print, solder, flash and fix, it is the right one.
Maintenance, licence and what to check before you build
The repository was last pushed on 2026-09-13 and is not archived, so the code and documentation are current as of that date. The repository has no published GitHub releases, which means the practical upgrade path is the main branch rather than tagged versions. That has a cost: without release tags you cannot pin a known-good firmware image, and a change to the detection thresholds in firmware/ lands on main without a version number to point at when something regresses. Budget for reading commits before you reflash a deployed unit.
The licence needs your attention rather than a summary from me. The repository reports NOASSERTION, and the top-level entries include both LICENSE.md and a LICENSES/ directory, which suggests more than one licence is in play across the firmware, hardware and documentation. The README has its own Licence section. If you plan to build units for an organisation, or to sell them, read LICENSE.md and the LICENSES/ directory yourself and get your own advice; the metadata alone does not tell you what you may do with the PCB files or the enclosure models.
The build itself is the ongoing cost. The README puts a full unit at £50 to £80 in parts and quotes 18 to 22 h on one battery charge, and it describes the e-paper screen as surviving a power cut, which matters for a device that is meant to sit unattended. Running several units is covered in the README under that heading: each alert sends an 18 byte LoRa packet to every other unit in range, so a site is a network rather than a set of independent boxes, and the range of that network depends on LoRa conditions the documentation does not quantify here.
Editorial conclusion
Adopt VolAnti if you need a cheap local tripwire for the last few hundred metres and you are willing to build and repair the hardware yourself; the repository ships firmware, PCB, BOM and a printable enclosure, and the README puts a full unit at £50 to £80 in parts. Do not adopt it if you need direction finding, long-range coverage or a certified product with a support contract: the array is explicitly a sensitivity device, not a direction finder, and the project states it is detection and alert only, with no jamming or interception. Before committing, verify the licence terms yourself, since the repository reports NOASSERTION rather than a named licence, and read docs/deploying.md and docs/test-results.md to see whether the 104 m figure matches the wind and noise conditions of your site.
Frequently asked questions
What does VolAnti detect, and how is that different from radio-based drone detection?
VolAnti detects the harmonic comb that a multirotor's propellers put into the air, rather than the control link between pilot and aircraft. That matters because a fibre-optic FPV drone emits no radio signal at all, so there is nothing for RF detection to find, but the motors still chop the air at the blade-passage rate.
How far away can VolAnti detect a drone?
The README reports 104 m measured detection against a hovering airframe in light wind. It does not claim that figure holds for a moving aircraft, a different propeller or a noisier site, so treat it as the measured best case rather than a specification.
Does VolAnti tell you which direction the drone is coming from?
No. The README states that the four-microphone array is a sensitivity device, not a direction finder, and that beamforming was tried at 79 mm and buys nothing. You get a detection and an alert, not a bearing.
What does VolAnti cost to build?
The README puts a full unit at £50 to £80 in parts. The repository includes the PCB, BOM and placement files under hardware/pcb/ and a printable enclosure under hardware/enclosure/, and it also documents a breadboard build for testing before you order a board.
Official sources
Add this badge to your README
If you maintain this project, the badge below links readers to this analysis and shows its maintenance status from the daily GitHub snapshot. Paste the markdown into your README; add ?metric=license or ?metric=stars to the image URL for a different field.
[](https://hysenlabs.com/projects/agamrossen-volanti)Star history chart for your README
[](https://hysenlabs.com/projects/agamrossen-volanti)Was this useful?