Isaac Lab 3.0 treats Isaac Sim as one physics backend among four, and pins each release to a Sim version
Unified framework for robot learning with multi-physics/renderer support
At a glance
- What is it?
- isaac-sim/IsaacLab is NVIDIA's GPU-accelerated Python framework for robot learning: reinforcement learning, imitation learning and post-training on top of Newton, OVRTX, OVPhysX or Isaac Sim. Version 3.0.0 loosens the dependency on Isaac Sim, but any workflow that still uses it is tied to a specific Sim release and brings proprietary components with it.
- Who is it for?
- Isaac Lab fits robotics teams that want ready-made robots and training environments wired to RSL RL, SKRL, RL Games or Stable Baselines, and that can run on NVIDIA GPU hardware. It is the wrong choice for a project that needs a fully open licence chain while relying on Isaac Sim, or for one stuck on an Isaac Sim version the compatibility table does not pair with the Isaac Lab line it wants.
- Can I use it commercially?
- Check first. The repository uses a licence we do not classify automatically, so read its LICENSE file before any commercial use.
- Is it still maintained?
- Yes. The repository received new commits within the last day.
- What is it written in?
- Mainly Python, according to GitHub's language statistics.
Answers come from the project's GitHub data, last synced on November 14, 2026, and from our analysis. They are not legal advice.
Star history
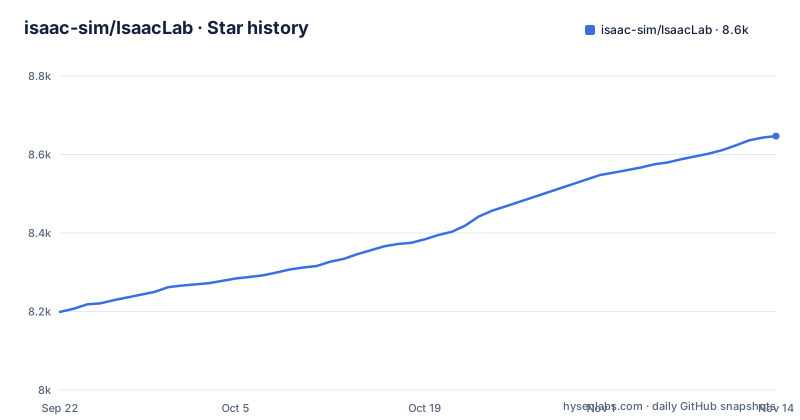
- isaac-sim/IsaacLab8,647 ★ · +448
| Repository | 2026-09-22 | 2026-11-14 |
|---|---|---|
| isaac-sim/IsaacLab | 8.2k | 8.6k |
448 Stars in the last 53 days, measured from the daily GitHub snapshot. Compare with other projects
Editorial analysis
Isaac Lab as a training layer over four physics and rendering backends
Isaac Lab is a Python framework for robot learning workflows: reinforcement learning, imitation learning and post-training. It does not do the physics itself. It runs on top of a backend, and version 3.0.0 lists four of them: Newton, OVRTX, OVPhysX and NVIDIA Isaac Sim. The backends provide physics and sensor simulation, and Isaac Lab provides the robots, environments, sensors and training hooks that sit above them.
That split is the main change to understand in the 3.x line. The README states that Isaac Lab "does not require Isaac Sim for every workflow." A team that only needs a rigid-body manipulation task can, in principle, stay off the Isaac Sim stack entirely, while a team that needs RTX-based cameras or LIDAR will be pulled toward the rendering backends.
The framework is GPU-accelerated throughout, and the project says it can run locally or be distributed across the cloud. The design target is clear from the feature list: many parallel simulations feeding a learning loop, which is the access pattern reinforcement learning needs.
Sixteen robots, thirty environments and four RL libraries out of the box
The reason to pick Isaac Lab over a bare simulator is the amount of task code that already exists. The README counts more than 16 robot models, from manipulators and quadrupeds to humanoids, and more than 30 ready-to-train environments.
Those environments are not tied to one training library. Isaac Lab names RSL RL, SKRL, RL Games and Stable Baselines as the reinforcement learning frameworks it trains with, and it also supports multi-agent reinforcement learning. For a lab that already has a preferred trainer, that means swapping the environment source without rewriting the training code around a new API.
On the simulation side, physics covers rigid bodies, articulated systems and deformable objects. Sensors include RGB, depth and segmentation cameras with camera annotations, IMU, contact sensors and ray casters. Imitation learning has its own extension, `isaaclab_mimic`, which ships with standalone scripts and a separate licence, covered further down. The full list of shipped environments lives on the documentation site under Available environments, which is where to check whether your robot and task already exist before writing one.
Every Isaac Lab line is pinned to specific Isaac Sim releases
Workflows that use Isaac Sim require a compatible version, and the README publishes the pairing as a table. The `release/3.0.0` branch and the `main` branch both target Isaac Sim 6.2. The `v3.0.0-EA` tag pairs with Isaac Sim 6.1, and `v3.0.0-beta2` with Isaac Sim 6.0. Going back to the 2.x line, `v2.3.X` works with Isaac Sim 4.5, 5.0 or 5.1, `v2.2.X` with 4.5 or 5.0, and both `v2.1.X` and `v2.0.X` only with 4.5.
The consequence is that an Isaac Lab upgrade is also an Isaac Sim upgrade. A project on `v2.3.X` running Isaac Sim 5.1 cannot move to 3.0.0 without moving to Isaac Sim 6.2 at the same time, and there is no row in the table pairing any 3.x release with a 5.x Sim. If your Isaac Sim install is managed by another team or baked into a cluster image, that coupling decides your Isaac Lab version for you.
The early 3.0 tags matter here too. Anything built against `v3.0.0-EA` targeted Isaac Sim 6.1, one minor version behind the final release.
Cloning the default develop branch lands you outside the compatibility table
The repository's default branch on GitHub is `develop`. The compatibility table lists `release/3.0.0`, `main`, and a set of tags, but not `develop`. The README on the default branch says "this branch targets Isaac Sim 6.2", which is consistent with the release rows, yet a plain clone still gives you the branch where unreleased work lands.
For a reader, the practical rule is to check out a named target rather than accept the default. If you want a stable base for a paper or a long training campaign, use the `v3.0.0` release tag published on 2026-10-20, or the `release/3.0.0` branch. If you are reproducing someone else's results, find the tag they used and match it to the Isaac Sim row before installing anything.
The project is under active development: the last push was on 2026-11-02, the final v3.0.0 release followed the v3.0.0-EA tag of 2026-09-16, and an "Interactive browser demos" release appeared on 2026-10-15. That pace is good for fixes and bad for anyone who tracks `develop` without pinning.
Where to get Isaac Lab, and what to read before the first run
The README hands installation to the documentation site, linking the installation guide at isaac-sim.github.io/IsaacLab/main/source/setup/installation/index.html, and the rest of the onboarding lives on the same documentation site: a getting started tutorial, a reinforcement learning concepts page, how-to guides and the list of available environments.
The badges at the top of the README point at Python 3.12, Ubuntu 22.04 and Windows, which sets expectations for the host before you open the guide. The first real decision in that guide is the backend. If your task needs Isaac Sim, install the Isaac Sim version from the compatibility table first and only then the matching Isaac Lab branch or tag. If it does not, the 3.x line lets you start from one of the other backends.
GPU requirements belong to the same step. The framework is GPU-accelerated by design, and the hardware you need depends on the backend and the sensors you simulate, so go through the installation guide before allocating a machine. For failures, the project points to a troubleshooting page on the documentation site, and Isaac Sim problems go to the Isaac Sim documentation and NVIDIA forums rather than the Isaac Lab tracker.
BSD-3 on top, Apache 2.0 for isaaclab_mimic, proprietary terms underneath Isaac Sim
GitHub's licence detector reports this repository as NOASSERTION, and the README explains the mix. The Isaac Lab framework is released under BSD-3, in the LICENSE file. The `isaaclab_mimic` extension and its standalone scripts are under Apache 2.0, in LICENSE-mimic. Licence files for dependencies and assets sit in the `docs/licenses` directory.
The catch is the backend. The README notes that some workflows requiring Isaac Sim include components under proprietary licensing terms. The code in this repository is permissive, but a training pipeline that depends on Isaac Sim is not a fully open stack, and anyone redistributing a container image or shipping a product built on it needs to read those terms, not only the BSD-3 text.
This is where the multi-backend design of 3.0 has a second payoff beyond flexibility. A workflow that runs on a non-Isaac Sim backend avoids the Isaac Sim licence question for that workflow. Which backends carry which terms is something to confirm in `docs/licenses` and the backends' own documentation before committing a project to one.
Isaac Lab versus a bare physics engine such as MuJoCo
MuJoCo is a physics engine: it simulates bodies and contacts, and you bring the environments, the robot models and the training loop, either your own or from a framework layered on top. Isaac Lab sits one level higher. It ships robots and ready-to-train environments, connects them to existing RL libraries, and treats the physics engine as a backend you choose.
The difference shows up in what you write on day one. With a bare engine, the first week goes into environment code, observation and reward definitions, and vectorising simulations. With Isaac Lab, the first week goes into picking one of the 30 shipped environments, matching Isaac Lab to an Isaac Sim version if you need it, and getting the GPU stack installed. The cost is weight: Isaac Lab pulls in an NVIDIA GPU stack and, for Sim-based workflows, proprietary components and a strict version pairing.
Support channels follow the same structure. GitHub Discussions is for questions and feature ideas, and GitHub Issues is reserved for work with a definite scope and a clear deliverable, so a vague installation problem filed as an issue is in the wrong place.
Editorial conclusion
Isaac Lab fits robotics teams that want ready-made robots and training environments wired to RSL RL, SKRL, RL Games or Stable Baselines, and that can run on NVIDIA GPU hardware. It is the wrong choice for a project that needs a fully open licence chain while relying on Isaac Sim, or for one stuck on an Isaac Sim version the compatibility table does not pair with the Isaac Lab line it wants. Before installing, decide which backend your workflow needs, match the branch or tag to the Isaac Sim row in the README table (release/3.0.0 and main both target Isaac Sim 6.2), and read the hardware section of the installation guide.
Frequently asked questions
Is NVIDIA Isaac Lab free?
The Isaac Lab framework is released under the BSD-3 licence, and the isaaclab_mimic extension with its standalone scripts is under Apache 2.0. Some workflows that require Isaac Sim include components under proprietary licensing terms.
What is Isaac Sim vs Isaac Lab?
Isaac Lab is a robot learning framework that runs on physics and rendering backends, and Isaac Sim is one of those backends alongside Newton, OVRTX and OVPhysX. Isaac Lab does not require Isaac Sim for every workflow, but workflows that use it need a compatible version, such as Isaac Sim 6.2 for the release/3.0.0 branch.
What is Isaac Lab?
Isaac Lab is a GPU-accelerated, open-source Python framework from the isaac-sim organisation for robotics research workflows such as reinforcement learning, imitation learning and post-training. It ships more than 16 robot models and more than 30 ready-to-train environments.
How do you install Isaac Lab?
Installation steps are published on the Isaac Lab documentation site at isaac-sim.github.io/IsaacLab, under setup/installation. For workflows that use Isaac Sim, install the Isaac Sim version that the README's compatibility table pairs with your Isaac Lab branch or tag, for example Isaac Sim 6.2 for release/3.0.0.
Official sources
Add this badge to your README
If you maintain this project, the badge below links readers to this analysis and shows its maintenance status from the daily GitHub snapshot. Paste the markdown into your README; add ?metric=license or ?metric=stars to the image URL for a different field.
[](https://hysenlabs.com/projects/isaac-sim-isaaclab)Star history chart for your README
[](https://hysenlabs.com/projects/isaac-sim-isaaclab)Was this useful?