roboflow/notebooks reads as a package but is a folder of tutorials with no pin, no license, and a second org name in every Colab link
A collection of tutorials on state-of-the-art computer vision models and techniques. Explore everything from foundational architectures like ResNet to cutting-edge models like RF-DETR, YOLO11, SAM 3, and Qwen3-VL.
At a glance
- What is it?
- Sixty-one Jupyter notebooks covering detection, segmentation, tracking, OCR and pose work, indexed by a table the repository forbids you to edit by hand. Useful as a task-to-script map, useless as something you depend on: no install command, one 2022 release tag, and hosted-runtime links built from a different org path than the repository name.
- Who is it for?
- Treat this as a directory of starting scripts rather than a dependency: there is no package to import, no release that identifies a notebook set, and no license stated in the repository, so confirm the terms of this repository and of each upstream model before shipping anything derived from a notebook.
- Can I use it commercially?
- Not without permission. GitHub finds no licence file in the repository, and without a licence all rights are reserved by default: you may read the code but not reuse it. Check the README, or ask the authors, before using it.
- Is it still maintained?
- Yes. The repository last received commits 53 days ago.
- What is it written in?
- Mainly Jupyter Notebook, according to GitHub's language statistics.
Answers come from the project's GitHub data, last synced on November 13, 2026, and from our analysis. They are not legal advice.
Star history
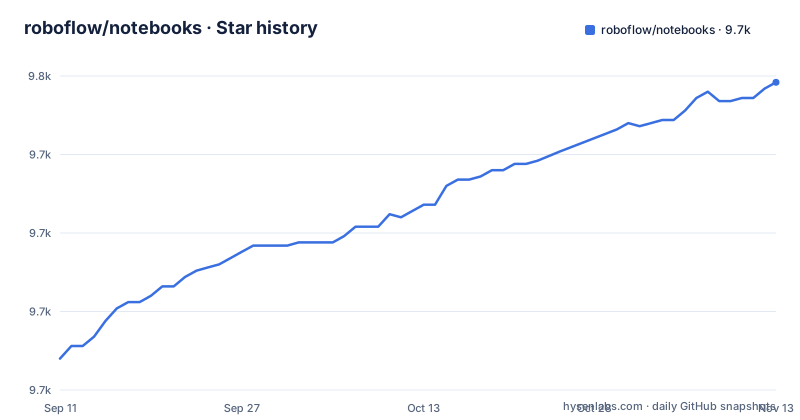
- roboflow/notebooks9,748 ★ · +88
| Repository | 2026-09-11 | 2026-11-13 |
|---|---|---|
| roboflow/notebooks | 9.7k | 9.7k |
88 Stars in the last 63 days, measured from the daily GitHub snapshot. Compare with other projects
Editorial analysis
Sixty-one notebooks sit behind one autogenerated table
The repository is a directory of Jupyter notebooks, not a distributable package. The index in the README is a section headed model tutorials (61 notebooks) whose rows each carry a file path under notebooks/, a Colab link, a Kaggle link, and pointers to whatever upstream project or paper the model comes from. The filenames are the only reliable statement of scope, and they name tasks directly: notebooks/rf-detr-keypoint-detection.ipynb, notebooks/train-yolo26-object-detection-on-custom-dataset.ipynb, notebooks/train-yolo26-instance-segmentation-on-custom-dataset.ipynb, notebooks/how-to-segment-images-with-segment-anything-3.ipynb, notebooks/how-to-segment-videos-with-segment-anything-3.ipynb, notebooks/open-vocabulary-object-detection-with-qwen3-vl.ipynb, notebooks/how-to-perform-ocr-with-glm-ocr.ipynb, notebooks/how-to-track-objects-with-bytetrack-tracker.ipynb, notebooks/object-detection-with-gemini-3-5-flash.ipynb, and notebooks/how-to-finetune-rf-detr-on-segmentation-dataset.ipynb. The top-level entries are .github/, .gitignore, CONTRIBUTING.md, README.md, assets/, automation/, and notebooks/. Nothing at the top level installs anything.
Colab and Kaggle links are generated from a roboflow-ai path
Every hosted-runtime link in the table is built from a github.com/roboflow-ai/notebooks path, while the repository itself is roboflow/notebooks. Copy the pair for the segmentation notebook exactly as the table writes it:
https://colab.research.google.com/github/roboflow-ai/notebooks/blob/main/notebooks/how-to-segment-images-with-segment-anything-3.ipynb
https://kaggle.com/kernels/welcome?src=https://github.com/roboflow-ai/notebooks/blob/main/notebooks/how-to-segment-images-with-segment-anything-3.ipynb
If a hand-written note or script of yours uses the roboflow path, you have produced a different URL from the one the table advertises, and whether both resolve is not something the table states. The Kaggle link is a kaggle.com/kernels/welcome URL with the notebook path passed as a src parameter.
The table header is a hard warning against editing the index
Above the rows sits an HTML comment that reads WARNING: DO NOT EDIT THIS TABLE MANUALLY. IT IS AUTOMATICALLY GENERATED. and then HEAD OVER TO CONTRIBUTING.MD FOR MORE DETAILS ON HOW TO MAKE CHANGES PROPERLY, with a marker named AUTOGENERATED-NOTEBOOKS-TABLE just above it. The top-level automation/ directory may be where the table is generated, but its contents are not shown. So a fork should not add a row by editing README.md and should go to CONTRIBUTING.md. The column header also advertises open in colab / kaggle / sagemaker studio lab, a third runtime, while the visible rows populate only the first two. Read the header as a schema with a half-filled field.
The 1.0.0 tag predates every notebook the table lists
The only release is 1.0.0, published 2022-12-01, and the last push to the main branch is dated 2026-09-22. That gap is the whole maintenance story: commits keep arriving, tags do not. The consequence is that you cannot pin this collection. If a notebook stops working because a hosted runtime, a public checkpoint, or a dataset URL changed, there is no earlier release to return to, and the 1.0.0 tag identifies no particular set of notebooks. A tutorial collection has good reason to age, but it means the reader is the person who finds the breakage, with no version history to bisect.
Filenames disagree with the greeting about which model version is taught
Three lists of models in this repository do not match. The repository description names ResNet, RF-DETR, YOLO11, SAM 3, and Qwen3-VL. The greeting paragraph names YOLOv11, SAM 2, Florence-2, PaliGemma 2, and Qwen2.5-VL, and names the task set as object detection, segmentation, pose estimation, data extraction and OCR. The table filenames go further still, with YOLO26 in two training notebooks, SAM 3 in the image and video segmentation notebooks, Qwen3-VL in the open vocabulary notebook, a Gemini model for object detection, GLM-OCR for OCR, and ByteTrack for tracking. A reader who skims the greeting to decide what is covered will not learn that YOLO26 notebooks exist or that the Qwen path has moved to Qwen3-VL. Use the filenames, and treat the greeting as an older snapshot of the same list.
First run is a hosted runtime link, not an install command
The top level has no package manifest, so there is nothing to import. Access is one notebook at a time, through the Colab and Kaggle links quoted above. The path is the unit of access rather than a package name, which is why the image segmentation tutorial and the video segmentation tutorial are two separate files that you reach independently. The consequence for a reader is that you never get a snapshot: you either point a hosted runtime at a blob URL, or you take the .ipynb file and own the environment it happens to describe. Neither route gives you a version you can diff against a colleague's, which is the first thing to settle before building on a tutorial here.
What the collection cannot do: record the dependency set you need
This repository cannot tell you which version of a training stack, a transformers release, or a detector package a given notebook expects, because there is no requirements file at the top level. It also gives you no single entry point across the collection: the repository and paper column sends you to different upstreams row by row, including roboflow/rf-detr, roboflow/trackers, ultralytics/ultralytics, facebookresearch/sam3, QwenLM/Qwen3-VL, and zai-org/GLM-OCR. So notebooks that touch rf-detr or trackers depend on those separate projects. If reproducibility matters to you, take the script, freeze the environment yourself, and pin the upstream project the table names.
What the collection cannot answer: licensing and model provenance
Two gaps matter before you build on these tutorials. The first is licensing: this repository's license is unknown and the top level has no LICENSE file, so code you copy out of a notebook arrives with no stated terms attached to it. The second is provenance: the repository and paper column is empty on some rows, and the object detection with Gemini notebook is one of them, with an empty complementary materials column too, which leaves a model name and a file path as the only references. The consequence is that neither column settles what you are allowed to ship, so check this repository's terms and the upstream model's terms as two separate questions before any fine-tuned result reaches a product.
Editorial conclusion
Treat this as a directory of starting scripts rather than a dependency: there is no package to import, no release that identifies a notebook set, and no license stated in the repository, so confirm the terms of this repository and of each upstream model before shipping anything derived from a notebook. If you need a reproducible fine-tuning run, copy the file, freeze its environment, and follow the upstream project named in the table separately, because that upstream, not roboflow/notebooks, is where the breaking changes arrive.
Frequently asked questions
How do I use roboflow/notebooks for a detection task?
You open one notebook by path in a hosted runtime. Each table row supplies a Colab link and a Kaggle link built from the same notebooks/ path,.
What is roboflow/notebooks, in short?
It is a collection of 61 computer vision tutorials kept as Jupyter notebooks, spanning object detection, segmentation, pose estimation, data extraction and OCR, with tracking, keypoint detection and open vocabulary work named in the table filenames.
Does roboflow/notebooks install as a Python package?
No. The top-level entries are .github/, .gitignore, CONTRIBUTING.md, README.md, assets/, automation/ and notebooks/, and none of them is a package manifest, so there is nothing to pip install or import.
Can I pin a roboflow/notebooks version to reproduce a tutorial later?
No usable pin exists. The only release is 1.0.0 from 2022-12-01 while the last push to main is 2026-09-22, so that tag identifies no particular set of notebooks and gives you nothing to roll back to.
Why do the roboflow/notebooks Colab links use a roboflow-ai path?
The table builds every hosted-runtime link from a github.com/roboflow-ai/notebooks path, which is not the same string as the roboflow/notebooks repository name..
Where do I add a new tutorial to roboflow/notebooks?
Not by editing README.md. The table header carries a warning that the table is automatically generated and directs you to CONTRIBUTING.MD for how to make changes properly.
Official sources
Add this badge to your README
If you maintain this project, the badge below links readers to this analysis and shows its maintenance status from the daily GitHub snapshot. Paste the markdown into your README; add ?metric=license or ?metric=stars to the image URL for a different field.
[](https://hysenlabs.com/projects/roboflow-notebooks)Star history chart for your README
[](https://hysenlabs.com/projects/roboflow-notebooks)Was this useful?